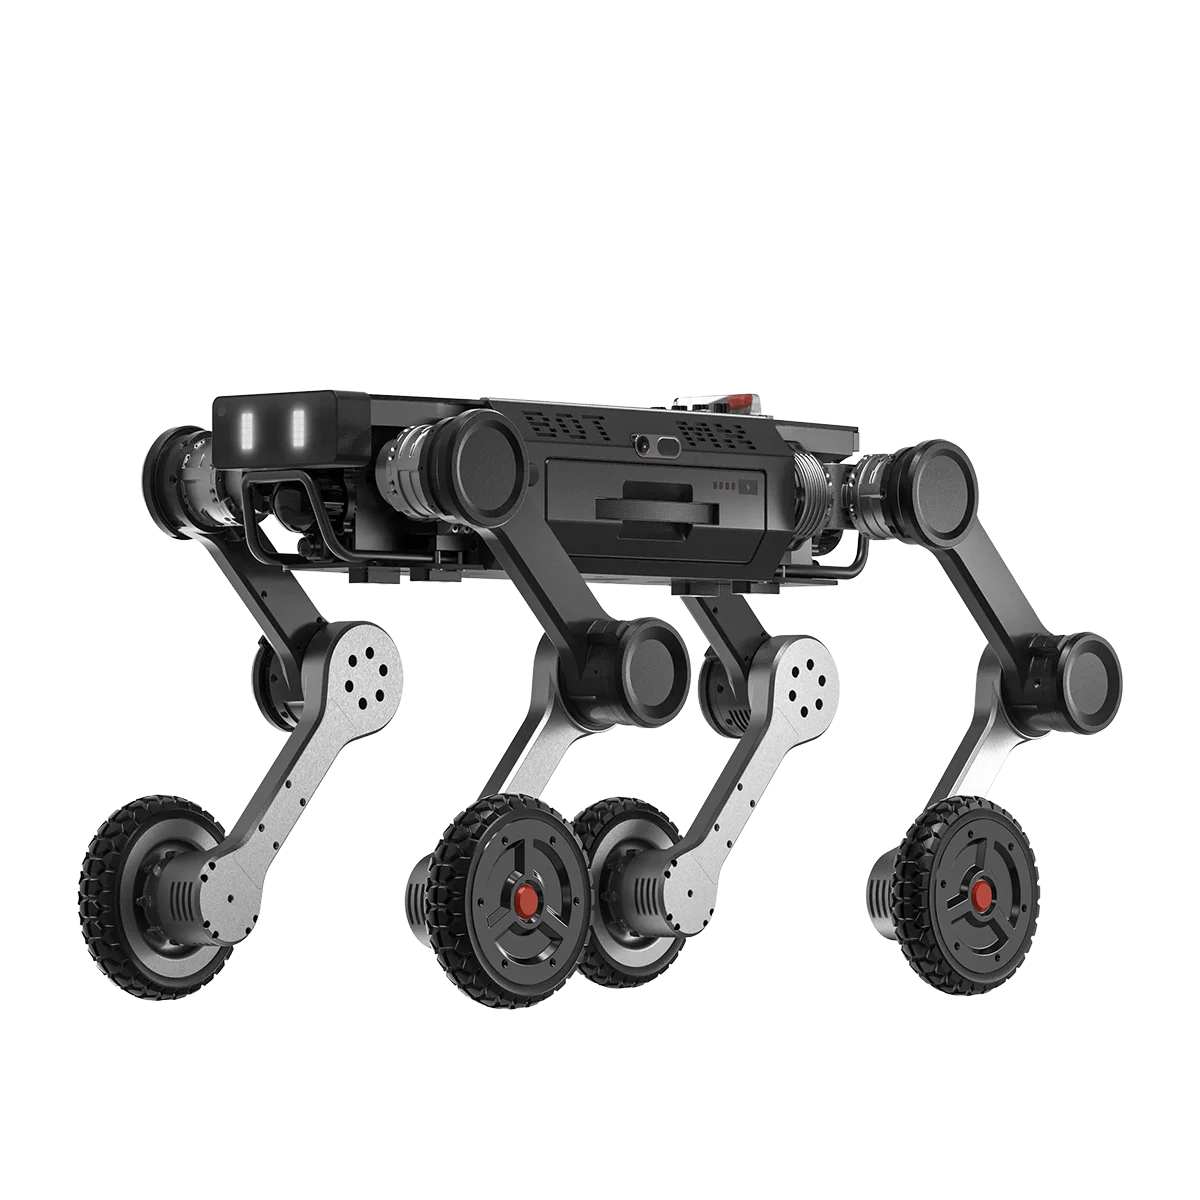
Lenovo Daystar Legged Robot
 Lenovo Daystar
The legged robot series covers MC, a quadruped at 20 kg with IP54, 15 kg static and 8 kg walking payload and 3.7 m/s; MX, a heavy-payload quadruped at 40 kg with IP67, 75 kg static and 25 kg walking payload, 6 m/s and 20 km; GS3.0, a hexapod at 68 kg with 70-100 kg continuous payload and 1.6 m/s; IS2.0, a hexapod with 18 Ah and 10 kg; IS, a hexapod at 37 kg with 30 kg static and 10 kg walking payload, 2 m/s and RK3588 + Orin NX; and IS Lite, a lightweight 15 Ah version.
- Weight
- ~40 kg
Starting price · MX
Visit websiteContact sales
Specifications
| Hardware | MXContact sales |
|---|---|
| Sensing | |
| Cameras | Yes (4 x fisheye GMSL cameras) |
| IMU | Yes |
| Computing | |
| Main processor | RK3588+Orin NX |
| Actuation | |
| Joint motors | 12 + 4 units |
| Joint torque | approx. 150 Nm |
| End effector | Not listed |
| Motion | |
| Max speed | 6 m/s |
| Max slope angle | 45° |
| Max step height | 80 cm |
| Max stair height | Not listed |
| Max payload | Not listed |
| Walking payload | 25 kg |
| Static payload | 75 kg |
| Power | |
| Battery capacity | 10 Ah * 2 |
| Walking runtime | 2-4 h/20 km |
| Charging | Charging dock recharging |
| Battery voltage | 54.00 V |
| Connectivity | |
| Wireless | Wi-Fi 5, 5 GHz |
| Expansion interfaces | View full specificationPower connector, LAN Ethernet port, USB port, serial port (RS485) |
| Structure | |
| Body size | Not listed |
| Weight | approx. 40 kg |
| Dimensions | View full specificationApprox. 860-1000 x 500 x 600 mm (leg configuration can be switched) |
| Folded dimensions | (860-1060) x 580 x 200 mm (leg configuration can be switched) |
| Shell material | Aluminium alloy + high-strength engineering plastic |
| Tire size | 190 mm outer diameter |
| Environment | |
| IP rating | IP67 |
| Operating temperature | -20~55°C |
Source: AI123Source updated