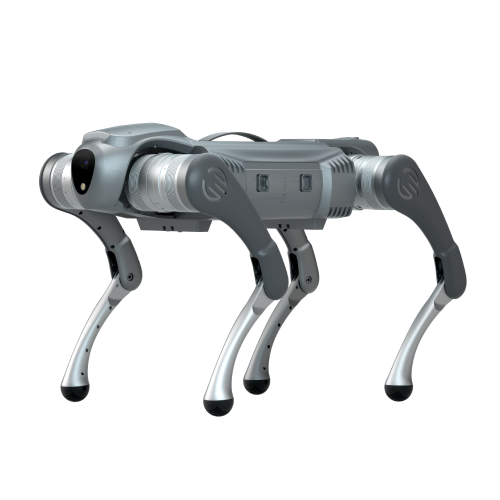
GALILEO C1
Galileo Tech
 Galileo Tech
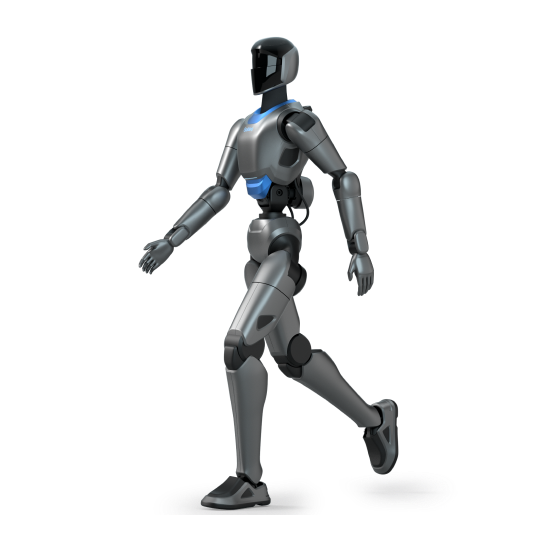
GALILEO GH-1 is a full-size bipedal humanoid for consumer and industrial scenarios. Thirty-one degrees of freedom across the body: 2 in the head, 7 per arm (3 shoulder, 1 elbow, 3 wrist), 6 per leg (3 hip, 1 knee, 2 ankle) and 3 at the waist; the body uses aluminium alloy and industrial plastic and weighs 45 kg, with in-house high-torque-density joint motors giving a locomotion speed of 4 m/s. The 10 Ah (444 Wh) battery charges in 2 hours with a 100-240 V charger input; external power outputs are 48 V / 24 V / 5 V (USB) and external communications are Ethernet/USB, with automatic charging optional. Environment perception uses a high-precision depth camera with an on-board edge computing unit, and dexterous hands are optional.
| Hardware | GH-1Not listed |
|---|---|
| Sensing | |
| Cameras | High-precision depth camera |
| Computing | |
| NPU edge compute | On-board edge computing unit |
| Actuation | |
| Full-body degrees of freedom | 31 |
| Arm degrees of freedom | 7 (3 shoulder; 1 elbow; 3 wrist) |
| Leg degrees of freedom | 6 (3 hip; 1 knee; 2 ankle) |
| Waist degrees of freedom | 3 |
| Head degrees of freedom | 2 |
| Arm length | 615 mm |
| End effector | Optional |
| Power | |
| Battery capacity | 10 Ah (444 Wh) |
| Charging | Optional |
| Connectivity | |
| Expansion interfaces | 48 V; 24 V; 5 V (USB) |
| Structure | |
| Body size | 1550 mm |
| Weight | 45 kg |
| Shell material | Aluminium alloy + industrial plastic |
Galileo Tech
Galileo Tech