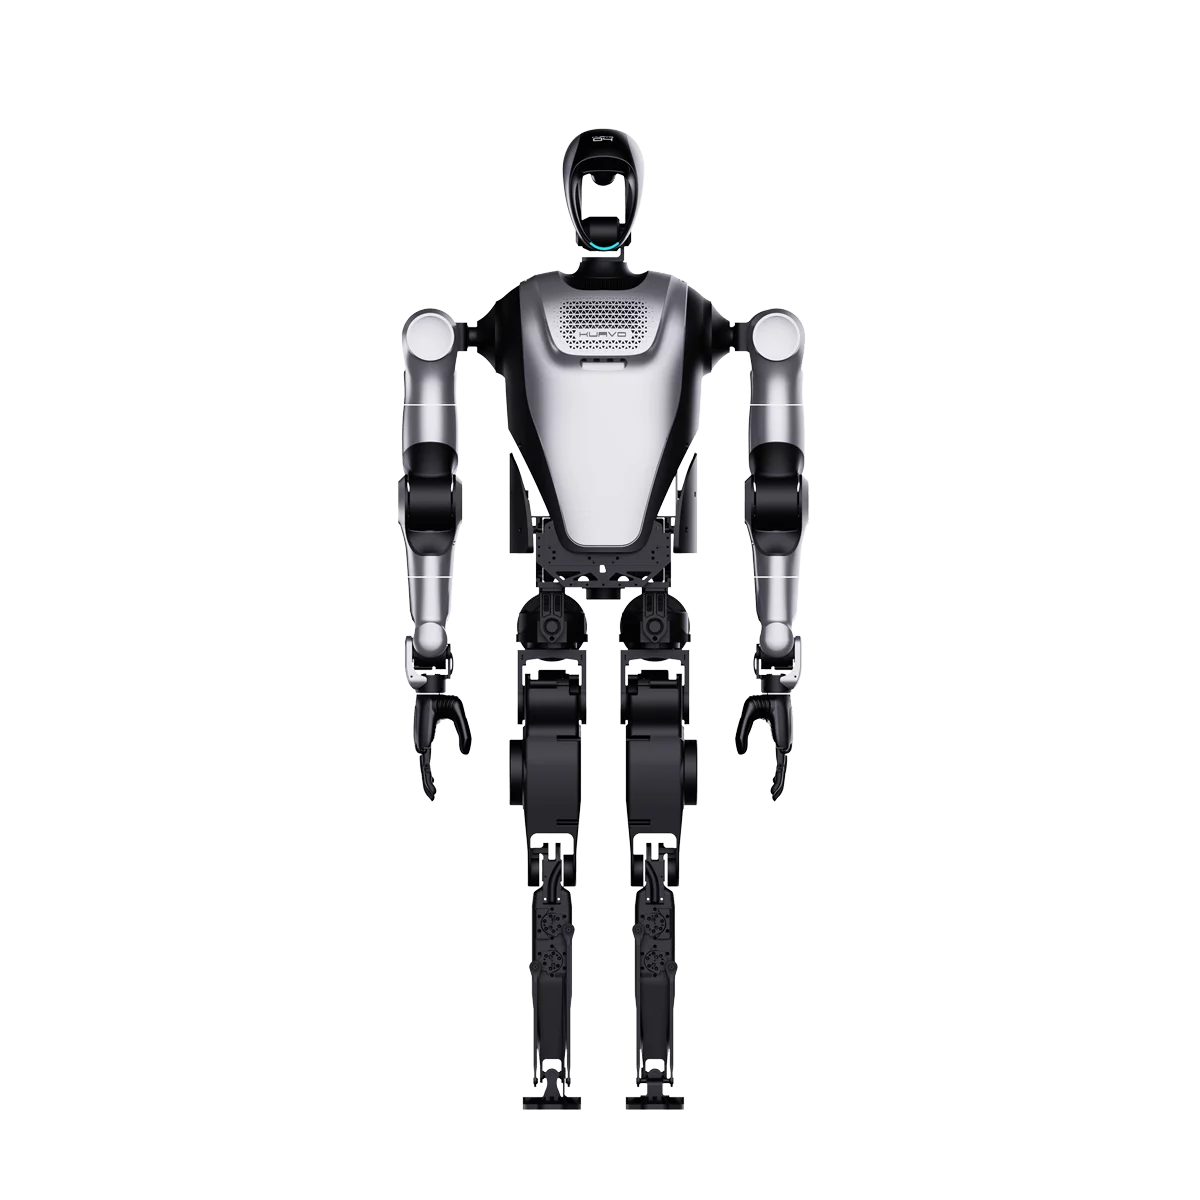
KUAVO 4Pro
Leju
 Leju
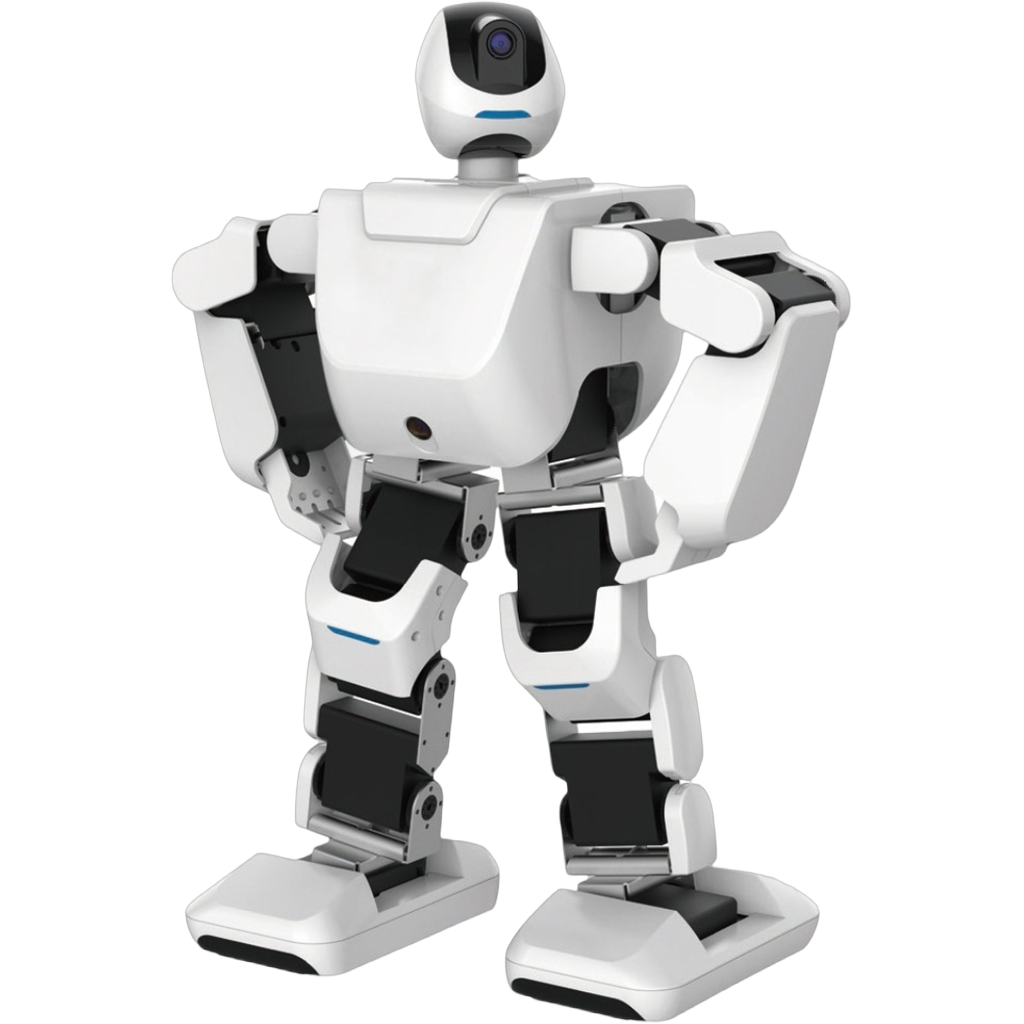
The AELOS open-source HarmonyOS edition is the first professional humanoid based on the open-source HarmonyOS (KaihongOS): 346 mm tall, 1.73 kg, 17 degrees of freedom across the body (head, shoulders, arms, legs and feet - 17 joints), driven by 17 high-torque servo actuators with a four-stage reduction gearbox. It runs an RK3568 development platform with a dual-computing architecture of high-performance STM32 and RK3568; audio output is 1.5 W with an MP3 module and speaker built in. A geomagnetic sensor and head and chest cameras are fitted, and seven wireless external expansion modules can coordinate over a soft bus for different scenario tasks; the lens is 60 degrees and 5 MP, with an NRF24L01 wireless gamepad. On the software side it is compatible with the PC edu application (for Mac and Windows), supports C/C++, Js/ArkTS and block-based programming, with lua/python3 also supported.
| Hardware | AELOS Open-Source HarmonyOS EditionNot listed |
|---|---|
| Sensing | |
| Cameras | View full specificationHead and chest cameras; 60 degree lens, 5 MP; camera model: USB + OV5640-160D |
| Speakers | View full specification1.5 W, with an MP3 module and speaker built in, supports music playback |
| IMU | MPU6050 |
| Computing | |
| Main processor | RK3568 |
| Memory & storage | 128 m |
| Actuation | |
| Full-body degrees of freedom | 17 |
| Arm degrees of freedom | 3 |
| Leg degrees of freedom | 5 |
| Head degrees of freedom | 1 |
| Power | |
| Battery capacity | 3200 mAh |
| Connectivity | |
| Wireless | 2.4 G group control; NRF24L01 wireless controller over 2.4 G |
| Structure | |
| Body size | 346 mm |
| Weight | 1.73 kg |
| Shell material | Aluminium alloy + PC/ABS plastic + photosensitive resin |
Leju
Leju