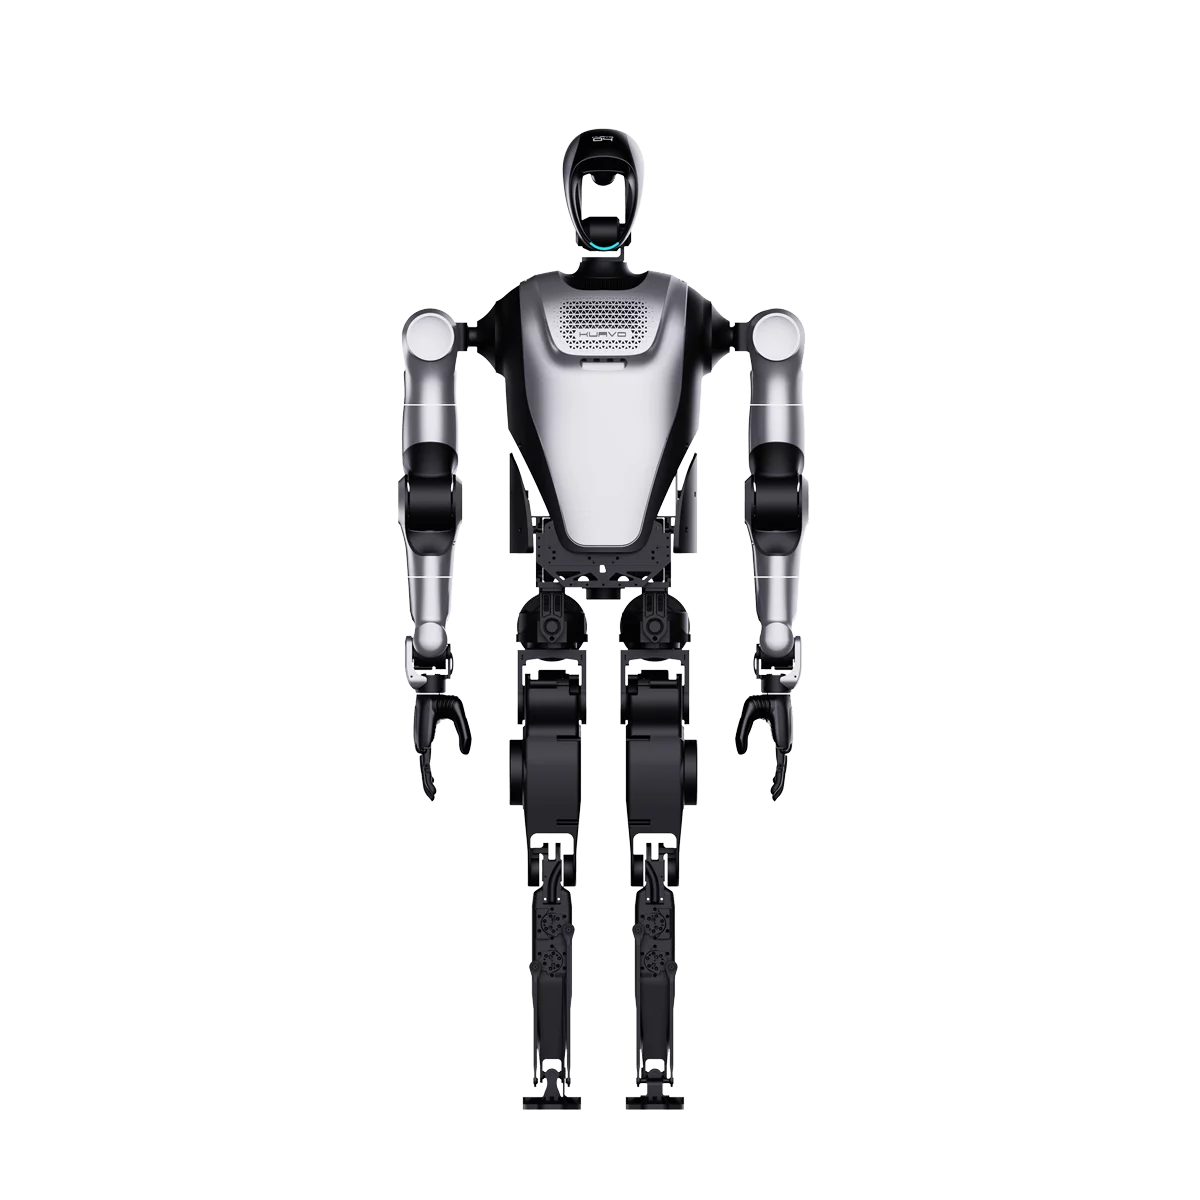
KUAVO 4Pro
Leju
 Leju
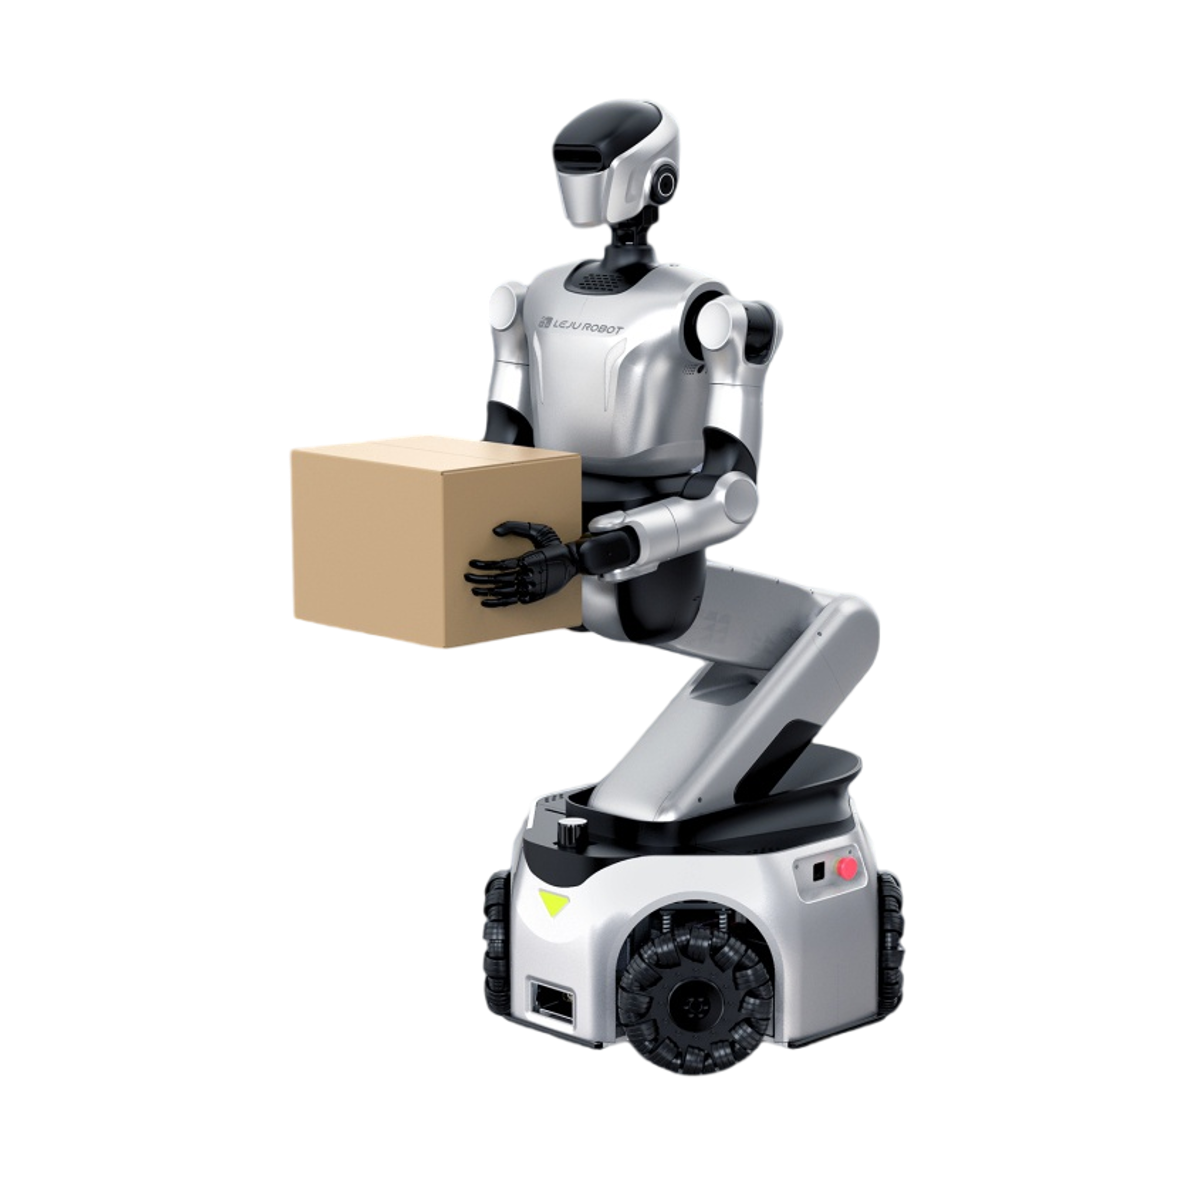
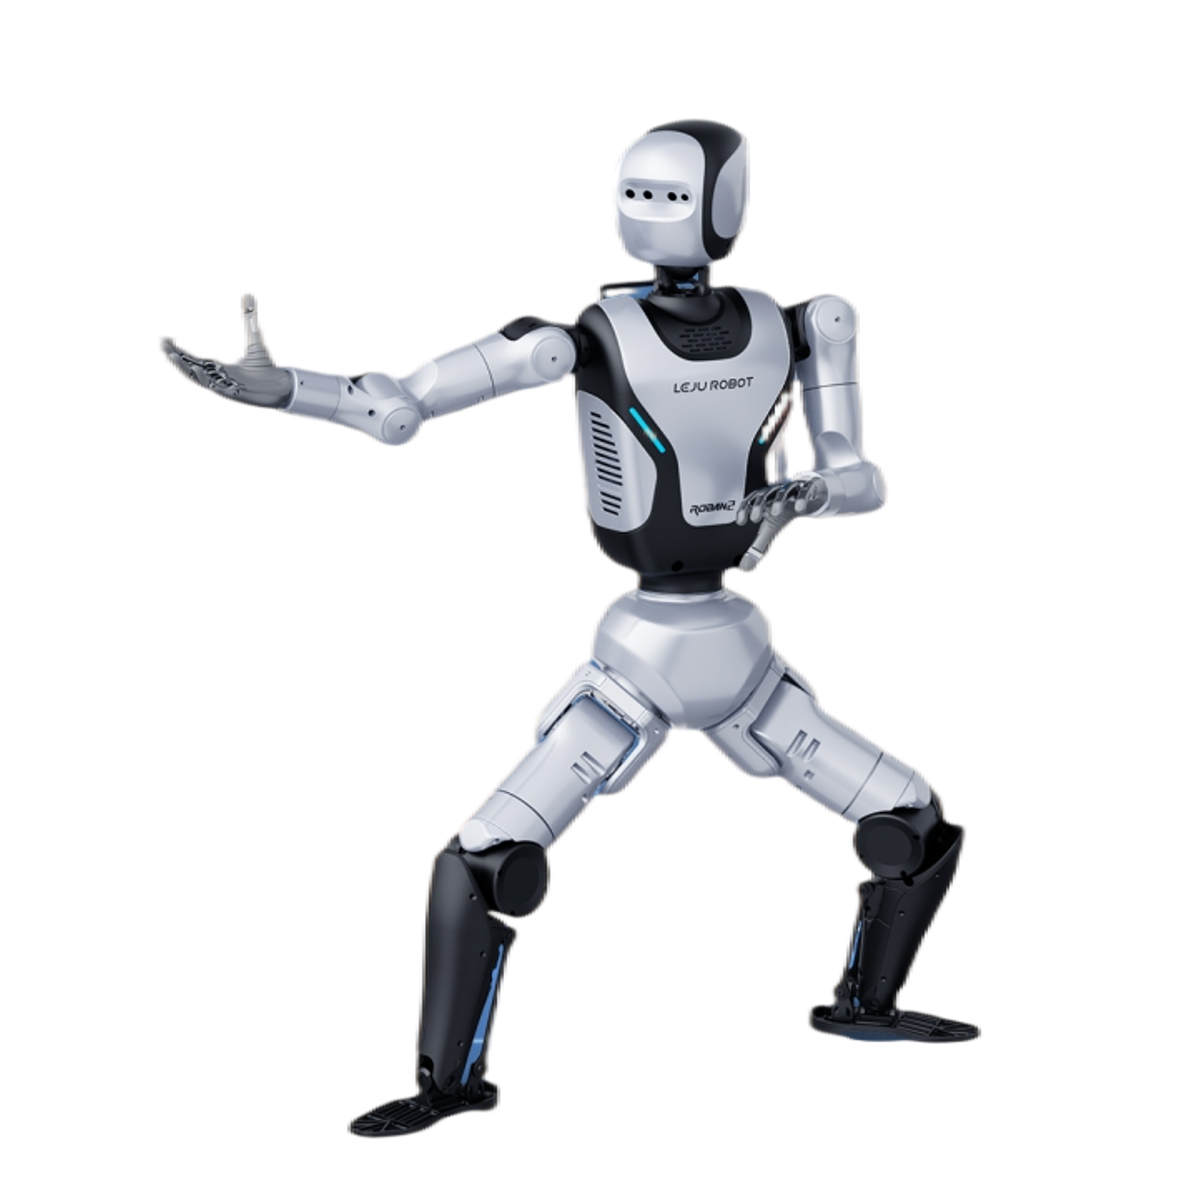
KUAVO 5 is a data-driven, general-purpose embodied AI humanoid built for industrial deployment at scale: 1730 mm tall and 63.5 kg, with 41 total degrees of freedom including a 6-degree-of-freedom dexterous hand, maximum motor torque of 400 N·m and a whole-body maximum payload of 20 kg, so squatting, bending and large-angle waist rotation are all achievable. Compute is selectable from 100 to 2070 TOPS, and four depth cameras plus a 3D LiDAR support semantic environment mapping and true vision-language navigation. The battery can be swapped quickly without powering down, so the line does not stop. End effectors can be specified as a two-finger gripper or a five-finger dexterous hand.
| Hardware | KUAVO 5-WContact sales |
|---|---|
| Sensing | |
| Cameras | 3 x depth cameras |
| Computing | |
| Main processor | Industrial computing unit |
| NPU edge compute | 100~275 TOPS |
| Actuation | |
| Full-body degrees of freedom | 36 |
| Dexterous-hand degrees of freedom | 6 |
| Waist degrees of freedom | >180° |
| Arm payload | 5 kg |
| End effector | View full specificationTwo-finger gripper / four-finger gripper / five-fingered dexterous hand |
| Power | |
| Removable battery | Not listed |
| Static runtime | ≥8 h |
| Connectivity | |
| Wireless | Wi-Fi 6, Bluetooth 5.2 |
| Structure | |
| Body size | 2200 mm |
| Weight | 245 kg |
| Shell material | Aluminium alloy and steel |
Leju
Leju