MagicBot X1
MagicLab
 MagicLab
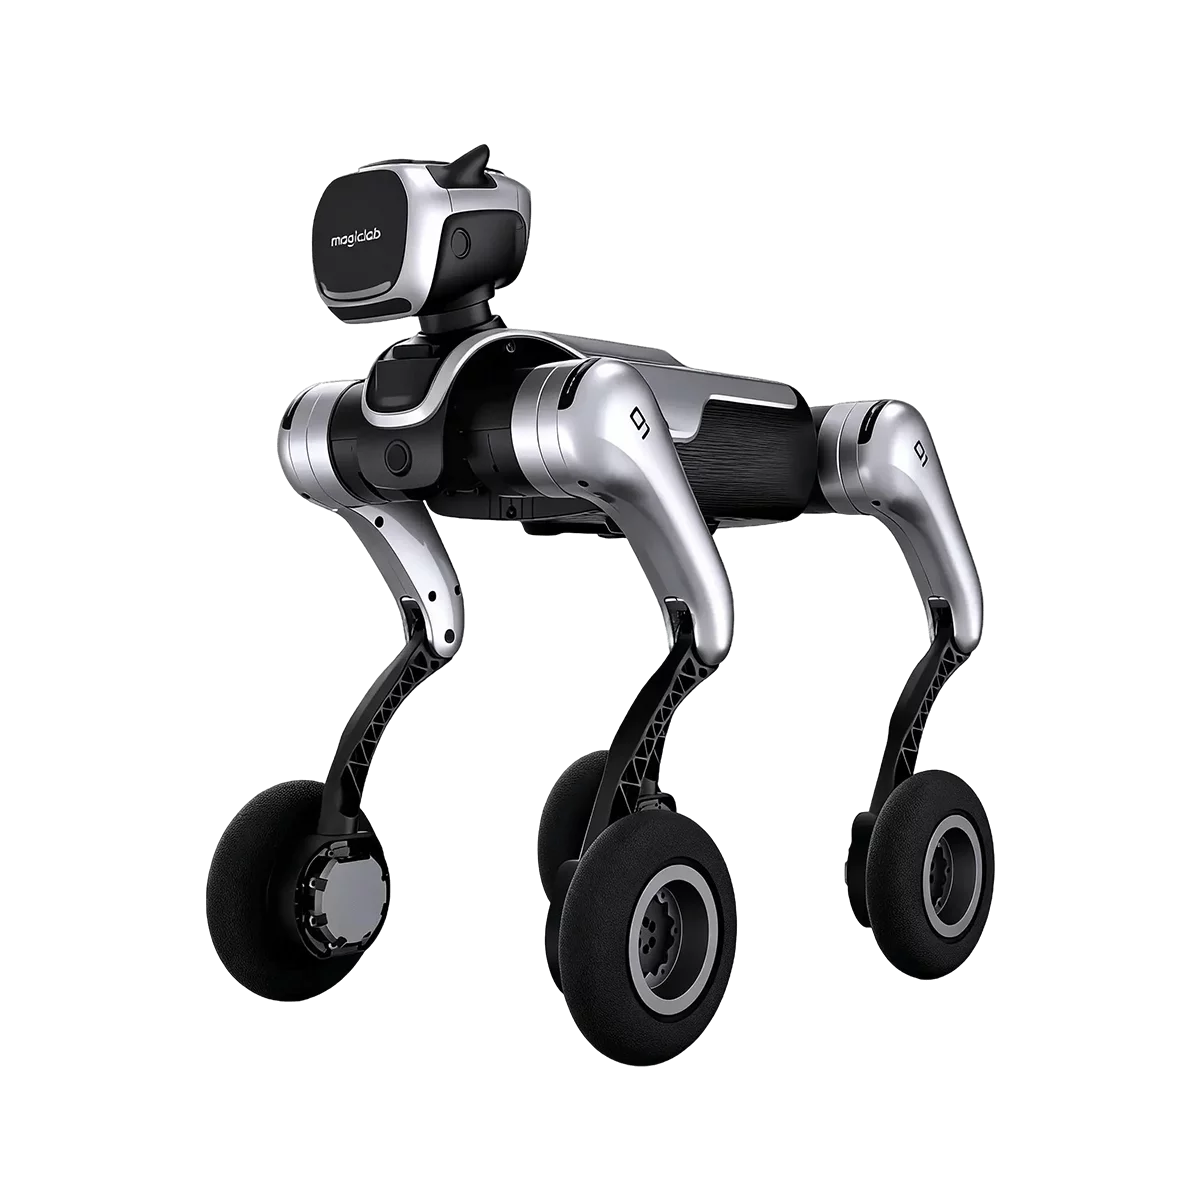
MagicDog-W is Magic Atom's wheeled quadruped robot, built around dual-form locomotion and synchronized intelligent control: wheel and leg motion are fused for fast travel, bidirectional climbing allows free forward and reverse movement, and it can hold an inverted posture under intelligent attitude control. Driven by 16+1 motors, the robot weighs 22.5 kg with battery and carries up to 10 kg, with a speed range of 0-3 m/s and a maximum slope of 40 degrees. Seven-inch pneumatic tires, together with an interface-rich back panel and expansion dock, accept external payloads such as LiDAR and gimbals, and a 157 TOPS high-performance compute module is standard. It supports 24 expression displays and touch interaction with at least 4 tactile methods, and a 29.6 V / 8,200 mAh battery delivers 2-4 hours of runtime with up to 8 hours of standby.
| Hardware | MagicDog-W$15,000 |
|---|---|
| Sensing | |
| Cameras | Stereo camera + depth camera + 4K HD camera + fisheye camera |
| Microphones | Ring microphone |
| Computing | |
| NPU edge compute | 6 TOPS |
| Actuation | |
| Joint motors | 16+1 (headmotor) |
| Joint torque | 37.5 N.m |
| Motion | |
| Max speed | 0-3 m/s |
| Max slope angle | ≤ 40° |
| Max payload | max.10 kg |
| Power | |
| Battery capacity | 8200 mAh |
| Walking runtime | 2-4 h |
| Static runtime | Up to 8 h standby (measured) |
| Battery voltage | 29.6 V |
| Connectivity | |
| Wireless | WiFi5, 4 G module, BT5.0 |
| Structure | |
| Body size | 650 mm |
| Weight | 22.5 kg (with battery) |
| Dimensions | 670*350*650 mm |
| Folded dimensions | 720*500*290 mm |
| Shell material | Aluminium alloy + high-strength engineering plastic |
| Tire size | 7 inch pneumatic tyre |
| Environment | |
| Operating temperature | -5°~40° |
MagicLab
MagicLab