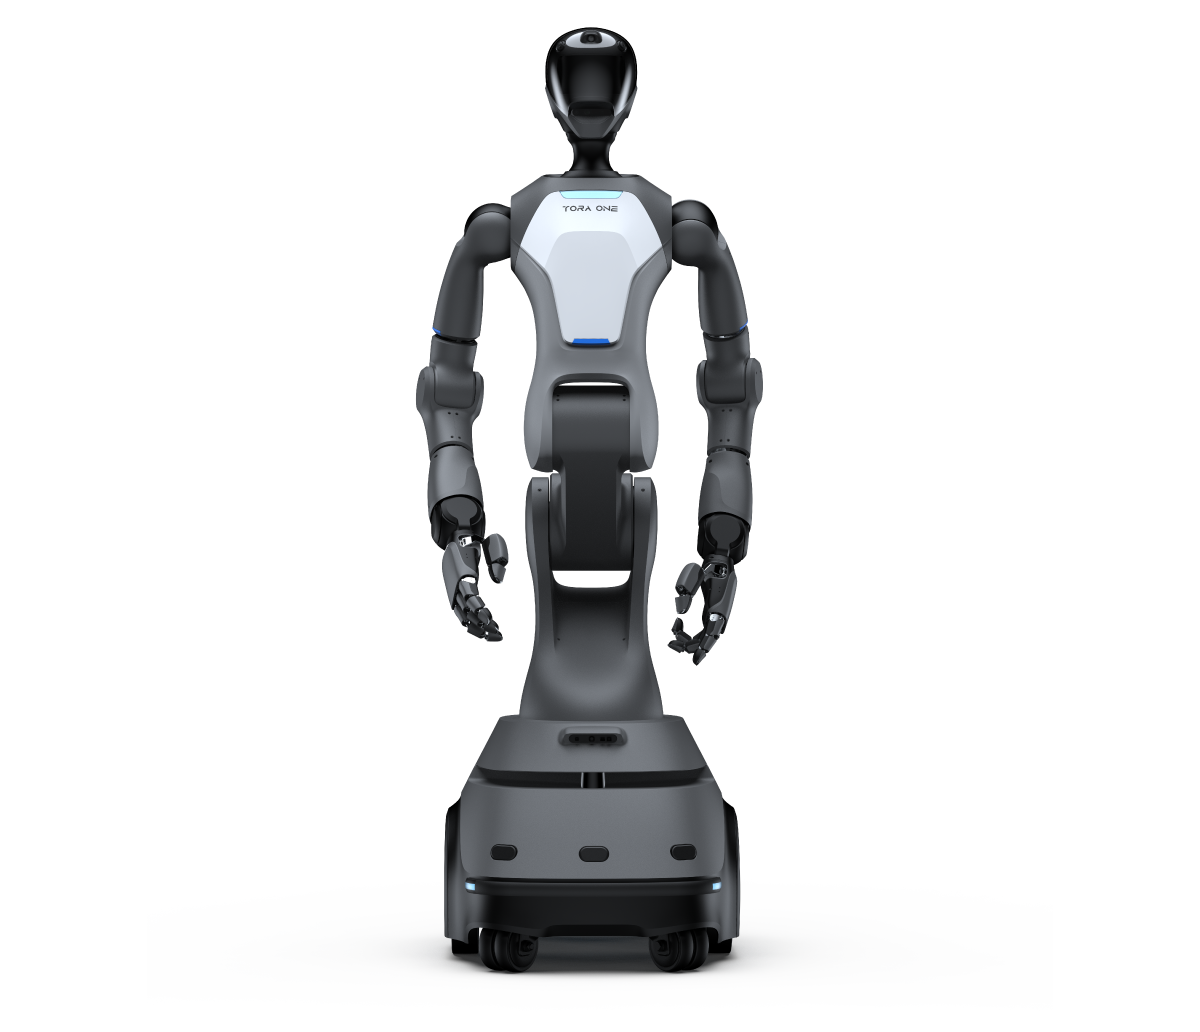
TORA ONE
 PaXini
TORA ONE is a multi-dimensional tactile humanoid, described by the developer as the industry's first. The whole machine folds: 1.46 m tall in the folded waist state and 1.86 m extended; the body has 21 degrees of freedom and the two hands 32, each a four-fingered 16-DOF dexterous hand (13 active plus 3 passive). A total of 2280 in-house ITPU multi-dimensional tactile sensing units across the body yield 6840 tactile signal channels, with fingertip force control accuracy of 0.01 N supporting 6D object pose recognition and grasping; a wheeled chassis with laser SLAM provides autonomous navigation, and a 40 Ah battery charges in 6 h for 8 h of runtime, covering logistics warehousing, medical and elderly care, industrial manufacturing and commercial service.
- Full-body DoF
- 53 DoF
- Rated arm payload
- ~5 kg
- Static runtime
- 8 h
Specifications
| Hardware | TORA ONENot listed |
|---|---|
| Sensing | |
| Cameras | View full specification5 RGB cameras (3 in the head + 1 in each hand) + 2 RGB-D cameras (1 in the head + 1 on the chassis) |
| Actuation | |
| Full-body degrees of freedom | 53 |
| Dexterous-hand degrees of freedom | 16 (13 active+ 3 passive) |
| Arm payload | Rated 5 kg |
| Arm length | 96.5 cm |
| End effector | Dexterous hand (coreless motor driven; 4 fingers) |
| Power | |
| Battery capacity | 40 Ah |
| Static runtime | 8 h |
| Structure | |
| Body size | View full specificationFoldable structure, 1.46 m with the waist folded and 1.86 m extended |