Monte01
Corenetic
 Corenetic
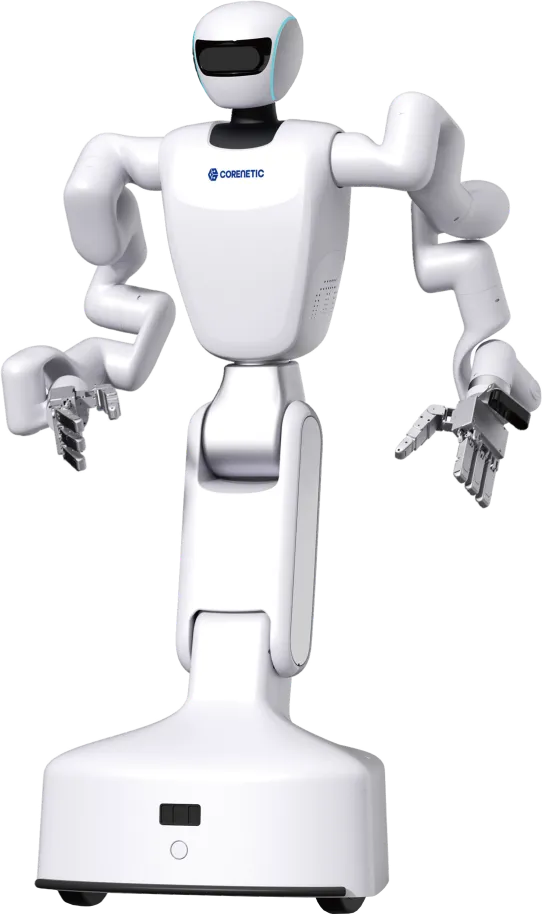
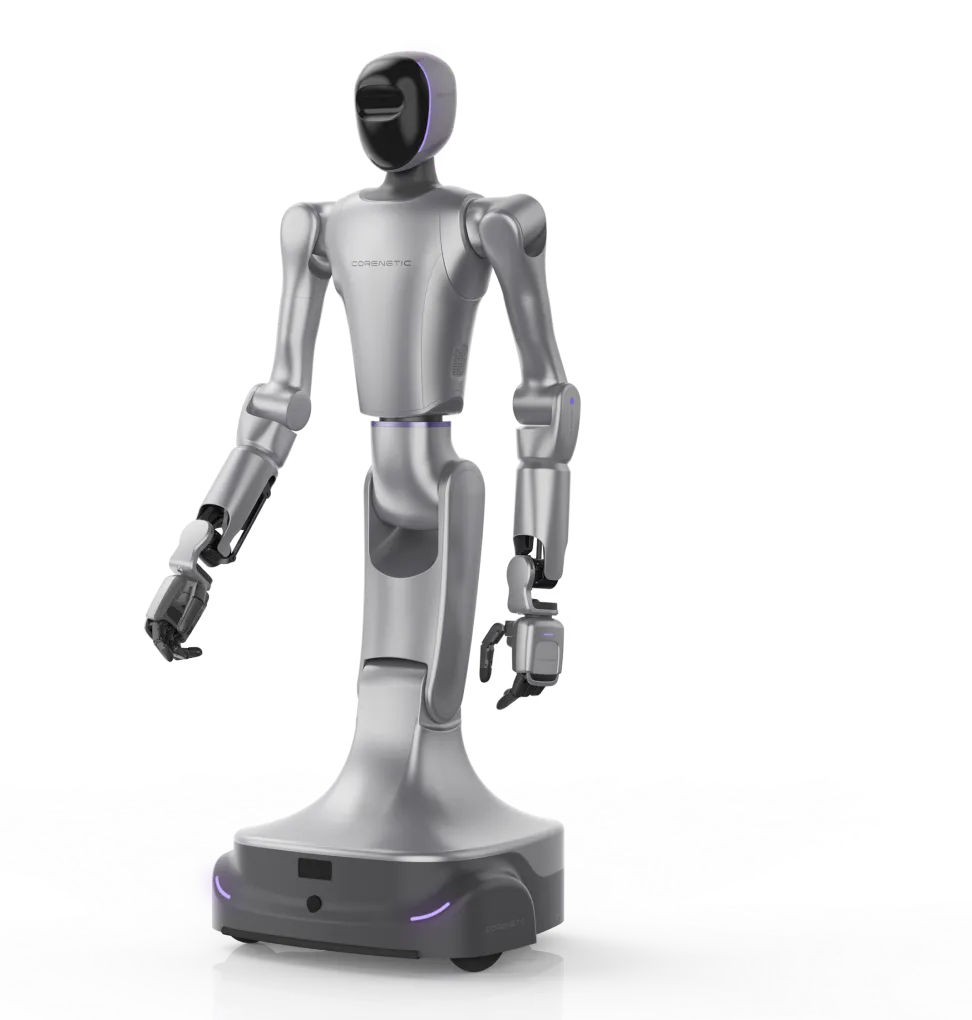
Monte02 is a general-purpose wheeled humanoid unveiled at the World Robot Conference in August 2025: 1.6 m tall, 100 kg, with 7-DOF arms giving 21 body degrees of freedom and 18 end-effector degrees of freedom, able to execute long-horizon, multi-stage dexterous manipulation tasks precisely. Two-wheel differential drive adapts to a variety of indoor floors, and fused LiDAR, ultrasonic and visual sensors with a high-precision vision module deliver autonomous navigation and obstacle avoidance. Natural-language and teaching input are supported with teach-one-do-ten task generalisation, achieving for the first time a fully autonomous closed loop across multimodal perception, decision and execution, for life sciences, smart manufacturing, warehousing and logistics and new agriculture, with a strategic partnership with MGI.
| Hardware | Monte02Not listed |
|---|---|
| Sensing | |
| Cameras | Head: 1 RGBD camera; arm end: 2×1 RGBD camera |
| Computing | |
| Main processor | x86 industrial real-time control board |
| NPU edge compute | Embedded AI processor, 200+ TOPS |
| Actuation | |
| Full-body degrees of freedom | View full specificationChassis 2 + waist 3 + head 2 + arm 7×2 + gripper 2 / dexterous hand 9×2 |
| Arm degrees of freedom | 7 DoF (SRS humanoid configuration) |
| Arm payload | 6.5 kg (at the end flange) |
| End effector | View full specificationAdaptive two-finger gripper / multi-finger dexterous hand, automatic quick-swap supported |
| Power | |
| Battery capacity | 51.2 V / 30 Ah |
| Static runtime | 8 h (typical operating conditions) |
| Charging | 2 h (fast-charging mode) |
| Connectivity | |
| Wireless | 2.4/5 GHz Wi-Fi 6, gigabit Ethernet, full-featured Type-C |
| Structure | |
| Weight | 100 kg |
| Shell material | View full specificationHigh-strength magnesium-aluminium alloy frame + ABS engineering plastic shell |
Corenetic