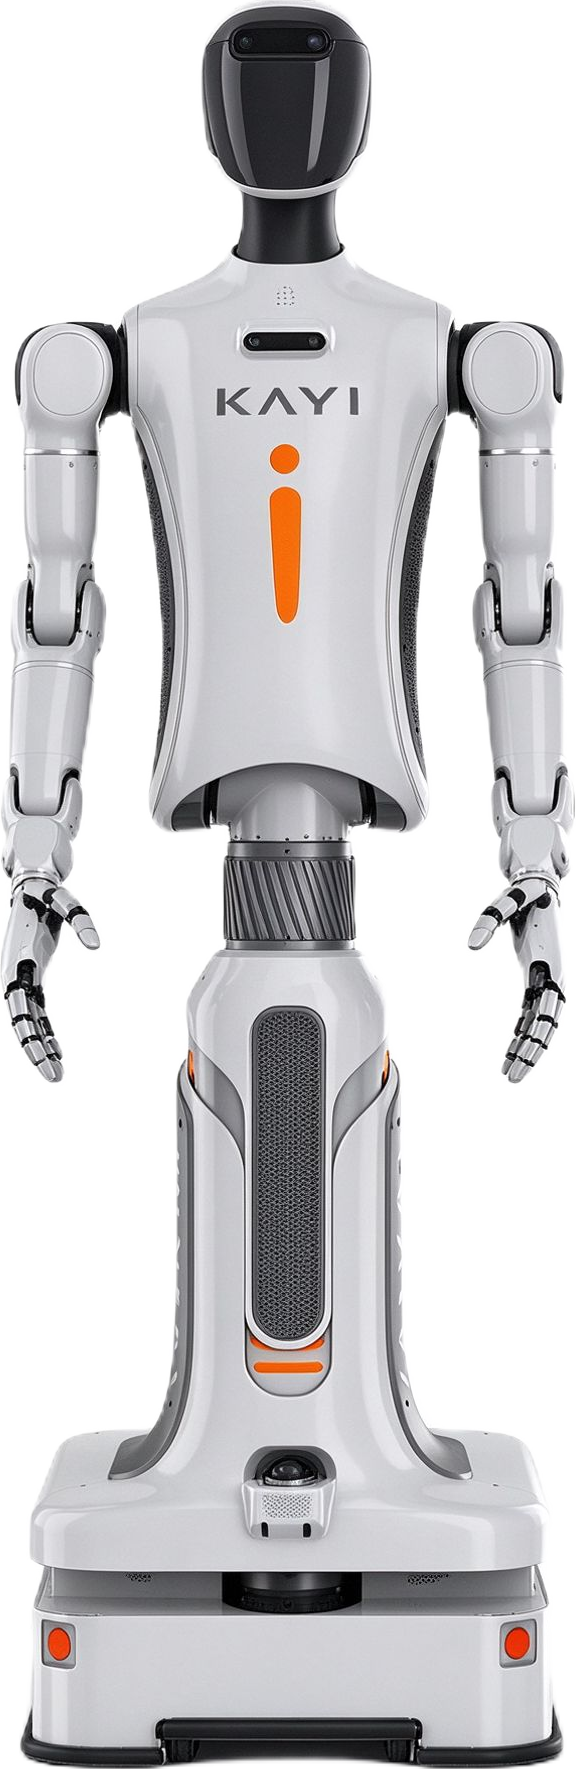
NAVIAI WA1
NAVIAI
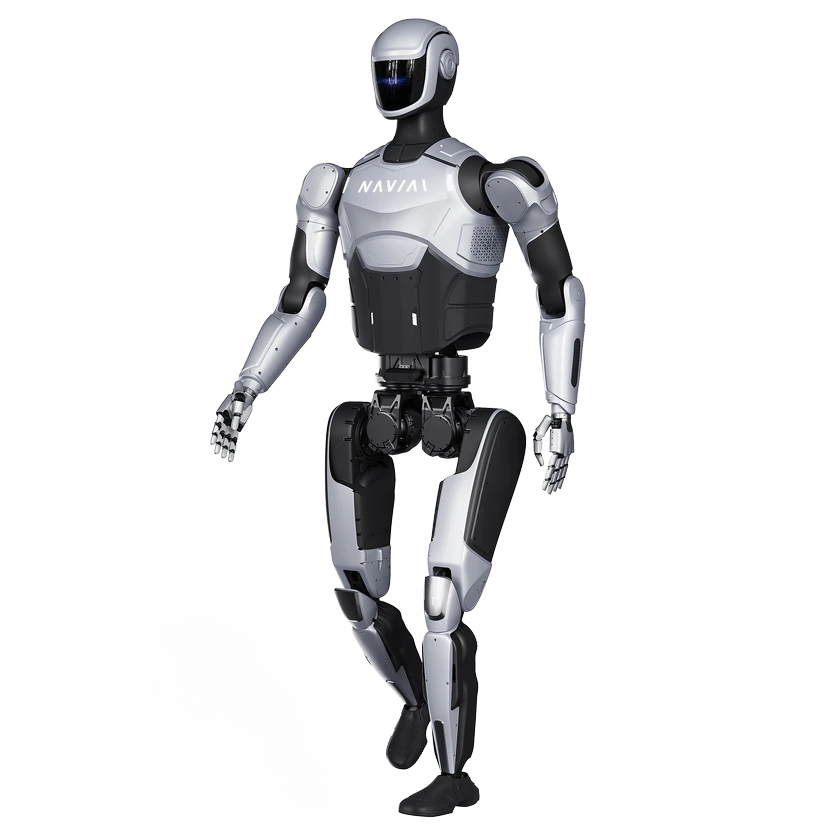
 NAVIAI
 I3 is an all-terrain multi-purpose bipedal robot with ample lower-body torque for demanding terrain. The machine has 37 degrees of freedom (6 per leg, 3 waist, 4 per arm, 6 per hand, 2 neck), a thigh pitch range of 200 degrees, peak joint torque of 360 N·m, top speed of 9 km/h, and maintains balance under external disturbance. It carries a 6-DOF dexterous hand with 10 N fingertip force and a 3 kg single-hand payload. Sensing includes a head-mounted surround multi-camera array, an IMU and a four-microphone array, with 275 TOPS of baseline computing power. It weighs 75 kg, runs 1.5 hours on a 1.08 kWh battery with fast manual battery swap, and coordinates all joints to accomplish complex tasks.
| Hardware | NAVIAI I3-SContact sales |
|---|---|
| Sensing | |
| Cameras | Head surround multi-camera: standard; hand cameras: optional |
| Microphones | 4-microphone array |
| Speakers | 30 W mono |
| IMU | Standard |
| Computing | |
| Main processor | perception: AGX ORIN 64 G 1 T; control: i7 (1.90 GHz) |
| Memory & storage | 64 GB RAM / 1 TB storage |
| NPU edge compute | 275 TOPS |
| Actuation | |
| Full-body degrees of freedom | 37 |
| Arm degrees of freedom | 4 |
| Leg degrees of freedom | 6 |
| Dexterous-hand degrees of freedom | 6 |
| Waist degrees of freedom | 3 |
| Head degrees of freedom | 2 |
| End effector | View full specificationDexterous hand 6 DoF (10 N fingertip force, 150°/s joint speed, 3 kg single-hand load) |
| Power | |
| Battery capacity | 1.08 kWh |
| Removable battery | Battery swap |
| Static runtime | 1.5 h |
| Charging | Battery swap |
| Connectivity | |
| Wireless | WIFI6, BLE5.2 |
| Expansion interfaces | View full specificationPICO-USB: standard; ORIN-USB: standard; DEBUG-USB: standard; Ethernet: standard; external emergency stop: supported |
| Structure | |
| Body size | 1770 mm |
| Weight | 75 kg |
NAVIAI
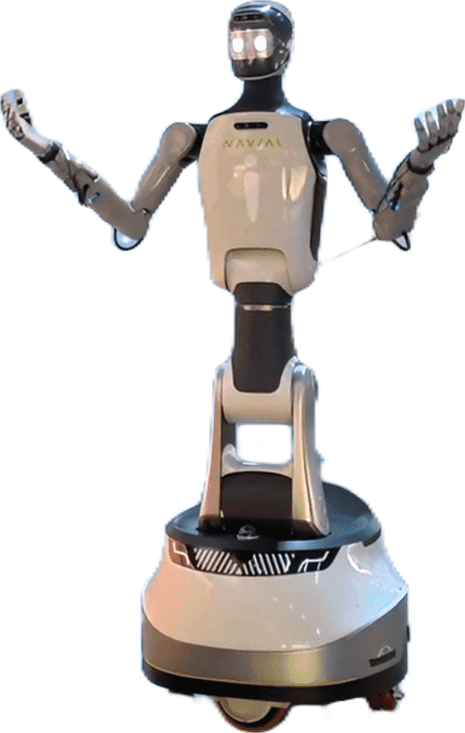
NAVIAI