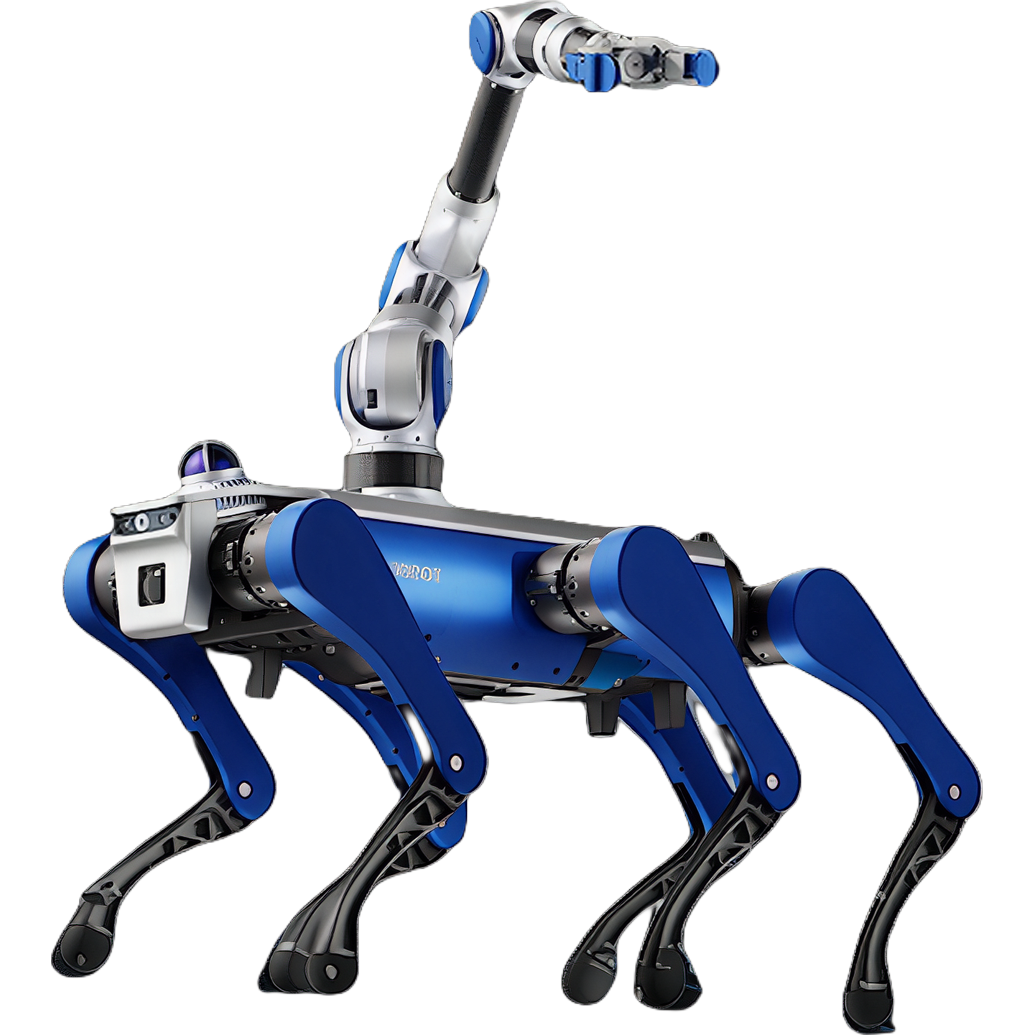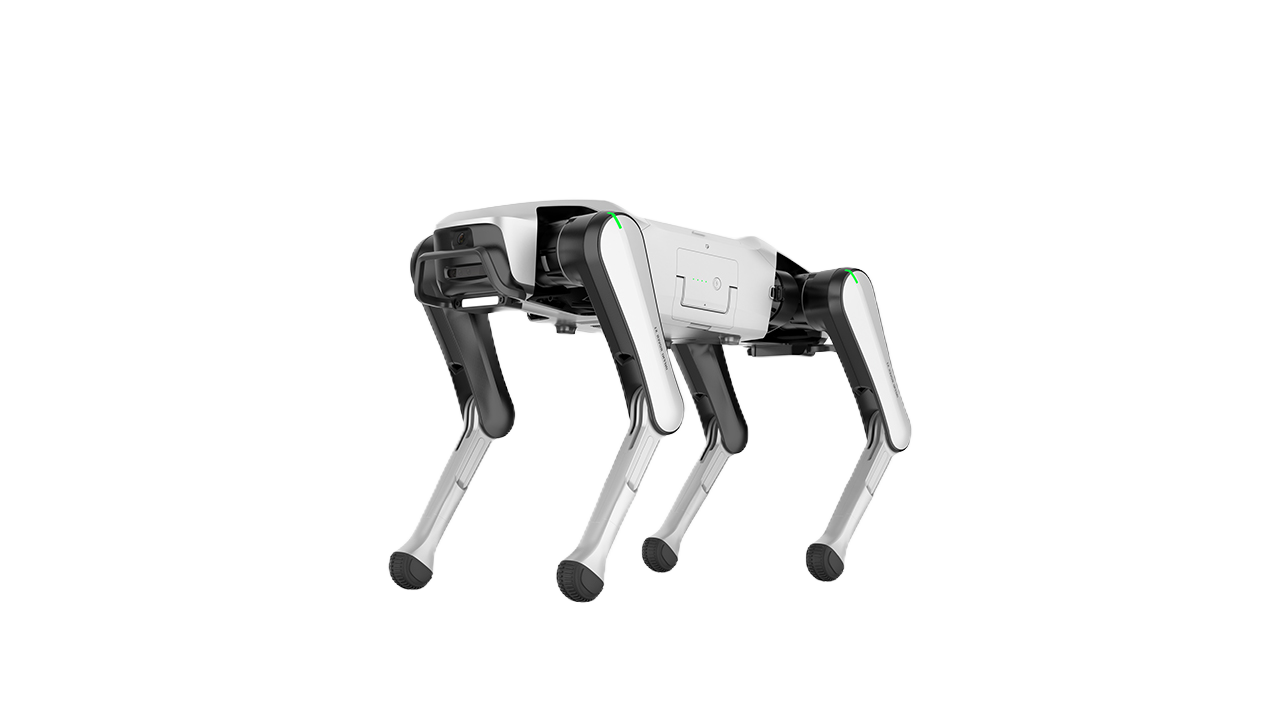
Rover X1
DOBOT
 DOBOT
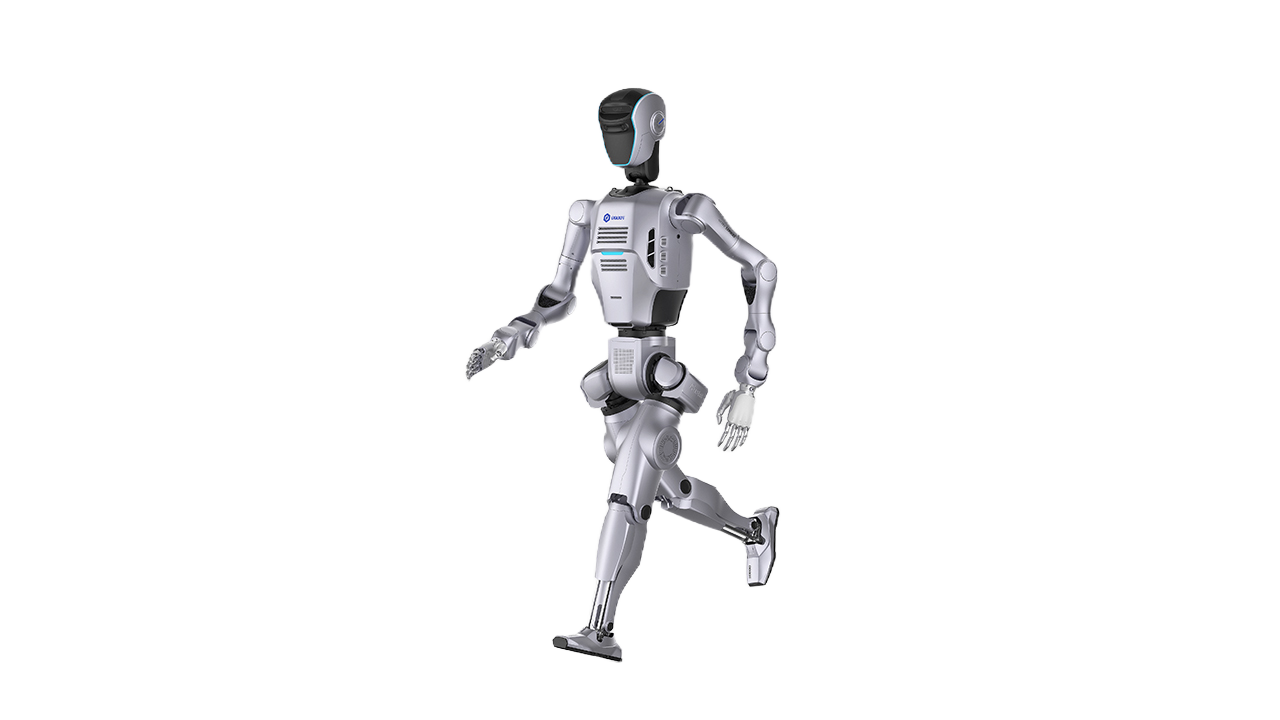
ATOM is a full-size general-purpose embodied AI humanoid, the world's first configuration to combine dexterous manipulation with straight-knee walking, targeting industrial-grade fine operation and cross-scenario generalised tasks. The upper body carries the neural-driven dexterous operation system (NDS), driven by human-like binocular RGB vision, delivering end-to-end autonomous operation of 28 upper-body degrees of freedom at a 200 Hz control frequency; locomotion uses the anthropomorphic straight-knee walking system (AWS), whose gait cuts energy consumption by 42 percent compared with bent-knee walking and adapts to workstations from 700 to 1000 mm high. The ROM-1 operation model has 100 million parameters with 24 Hz end-to-end control, autonomously decomposing tasks and making decisions; edge computing power reaches 7.7 times the industry standard, and multi-robot cooperative operation is supported.
| Hardware | ATOMContact sales |
|---|---|
| Sensing | |
| Cameras | Human-like binocular RGB vision |
| Computing | |
| NPU edge compute | 7.7 x the industry standard |
| Actuation | |
| Arm degrees of freedom | 28 |