ATOM
DOBOT
 DOBOT
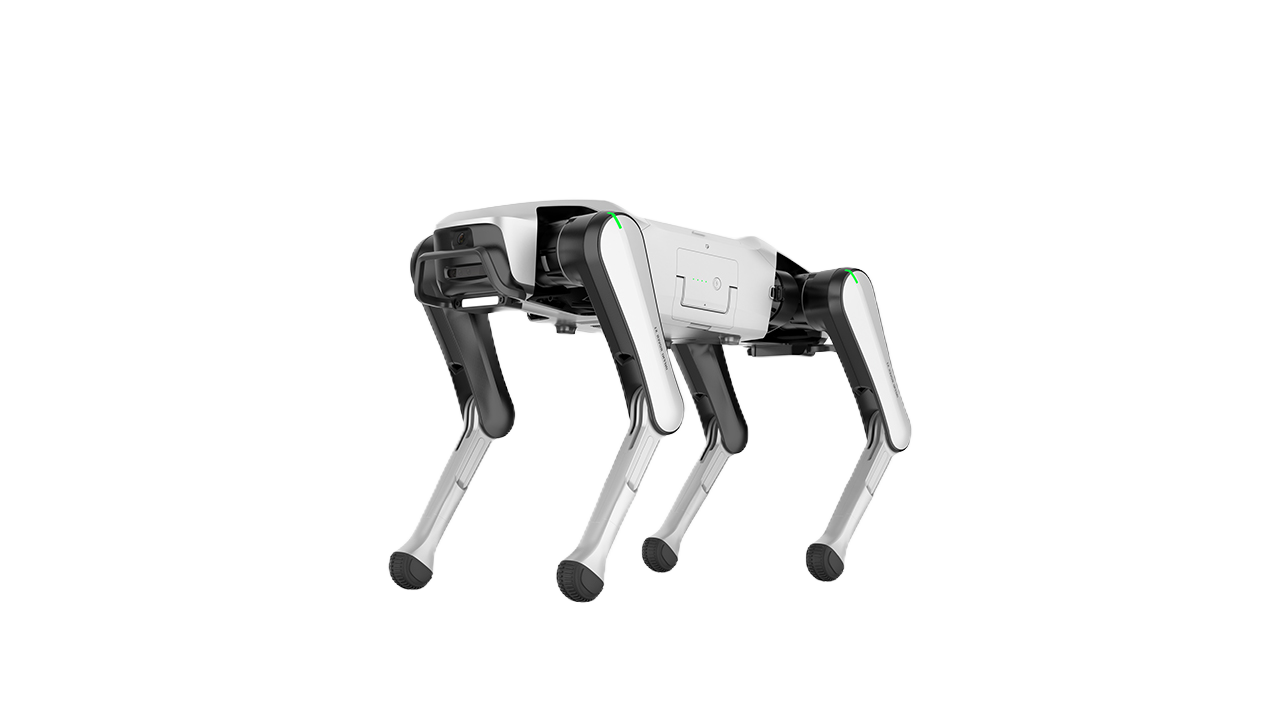
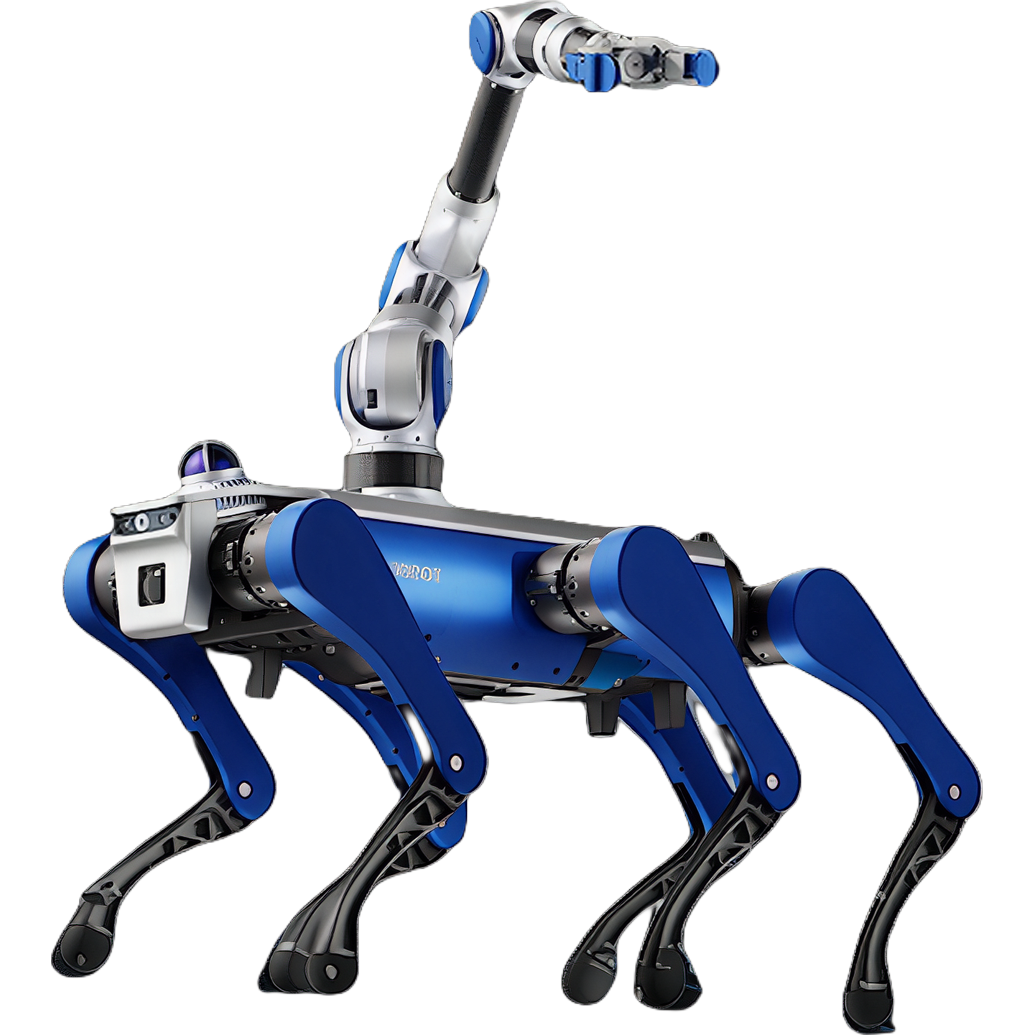
Hexplorer is a hexapod bionic robot: 86.3 x 47 x 48 cm standing, 18 degrees of freedom, about 20 kg, maximum walking speed 1.8 m/s, clearing 20 cm obstacles and handling 40 degree slopes, with a rated payload of 10 kg and a limit of 15 kg. It carries a Livox Mid360 LiDAR and a RealSense D435 depth camera, with a built-in 504 Wh battery giving 2.5 hours of runtime; the locomotion and control platform uses an X86_64 architecture with 40 TOPS of GPU computing, supporting walking, stair ascent and descent, obstacle negotiation and avoidance. Ubuntu 22.04 and ROS 2 Humble are preinstalled with an open SDK for custom algorithms and third-party hardware expansion.
| Hardware | Hexplorer¥69,888 |
|---|---|
| Sensing | |
| Cameras | Realsense D435 |
| IMU | IMU |
| Computing | |
| Main processor | X86_64 architecture; CPU: Core i7/i5, 6 cores 16 threads |
| NPU edge compute | GPU computing power: 40 TOPS |
| Actuation | |
| Full-body degrees of freedom | 18 |
| Joint torque | 33 Nm (knee joint) |
| Motion | |
| Max speed | 1.8 m/s |
| Max slope angle | 40° |
| Max step height | 20 cm |
| Max payload | Rated 10 kg, limit 15 kg |
| Power | |
| Battery capacity | 504 wh |
| Walking runtime | 2.5 h |
| Charging | Wireless automatic charging (planned for a later release) |
| Connectivity | |
| Wireless | View full specificationLong-range remote-control video transmission (planned for a later release) |
| Expansion interfaces | View full specificationCollaborative arm expansion supported (planned for a later release); long-range remote-control video transmission supported (planned for a later release); wireless automatic charging supported (planned for a later release) |
| Structure | |
| Body size | 48 cm |
| Weight | Approx. 20 kg for the unit, approx. 30 kg packaged |
| Dimensions | 86.3 cm x 47 cm x 48 cm |
| Folded dimensions | 73.4 cm x 47 cm x 24.4 cm |