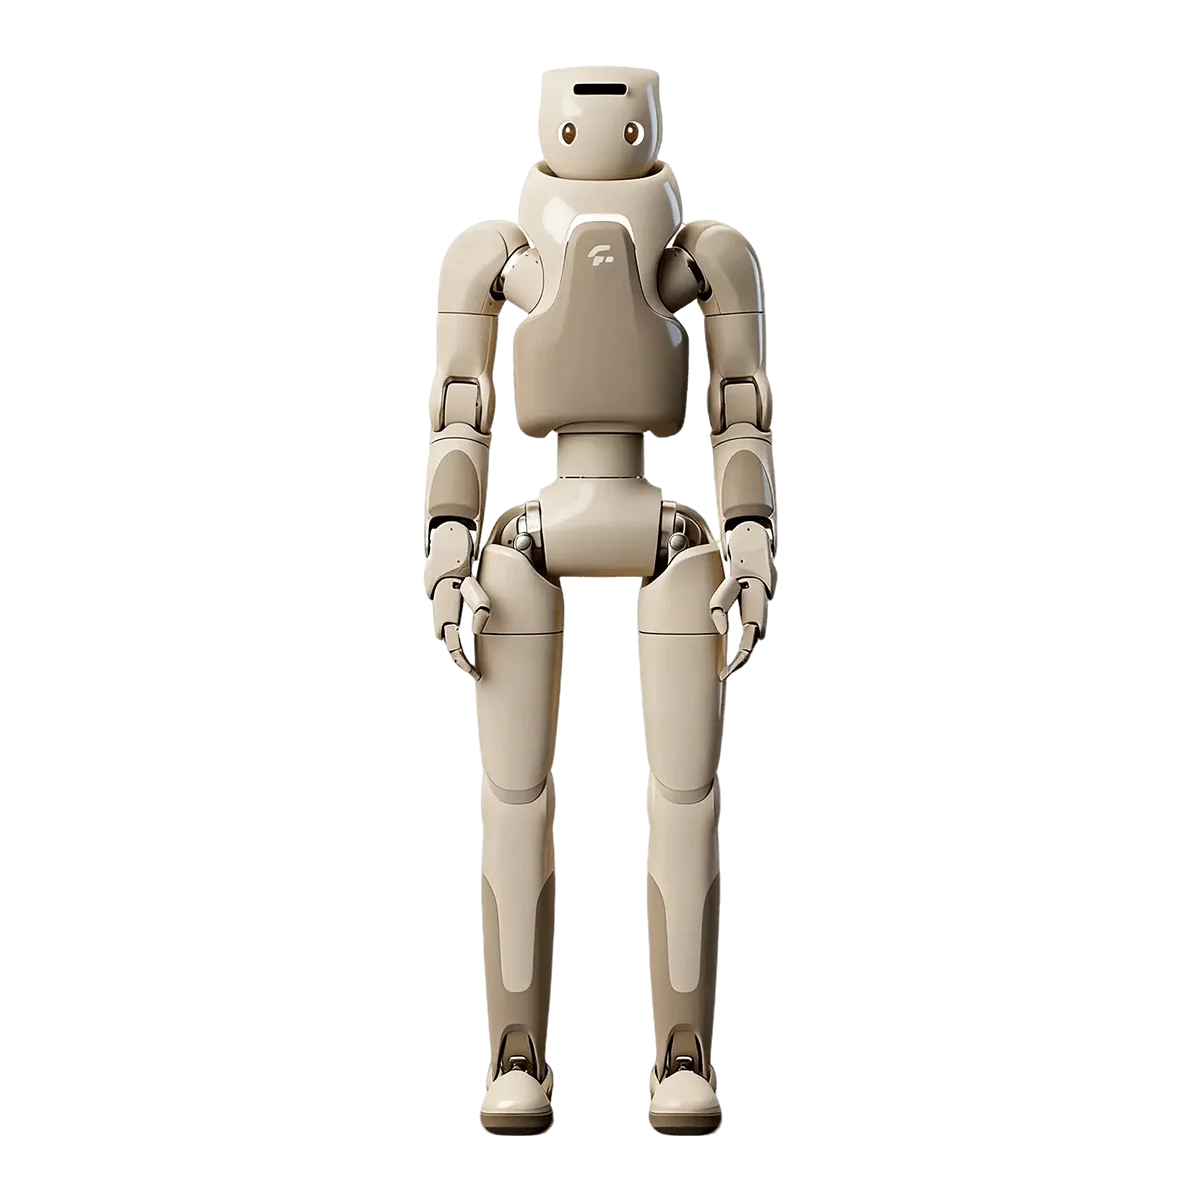
GR-3 Series
Fourier
 Fourier
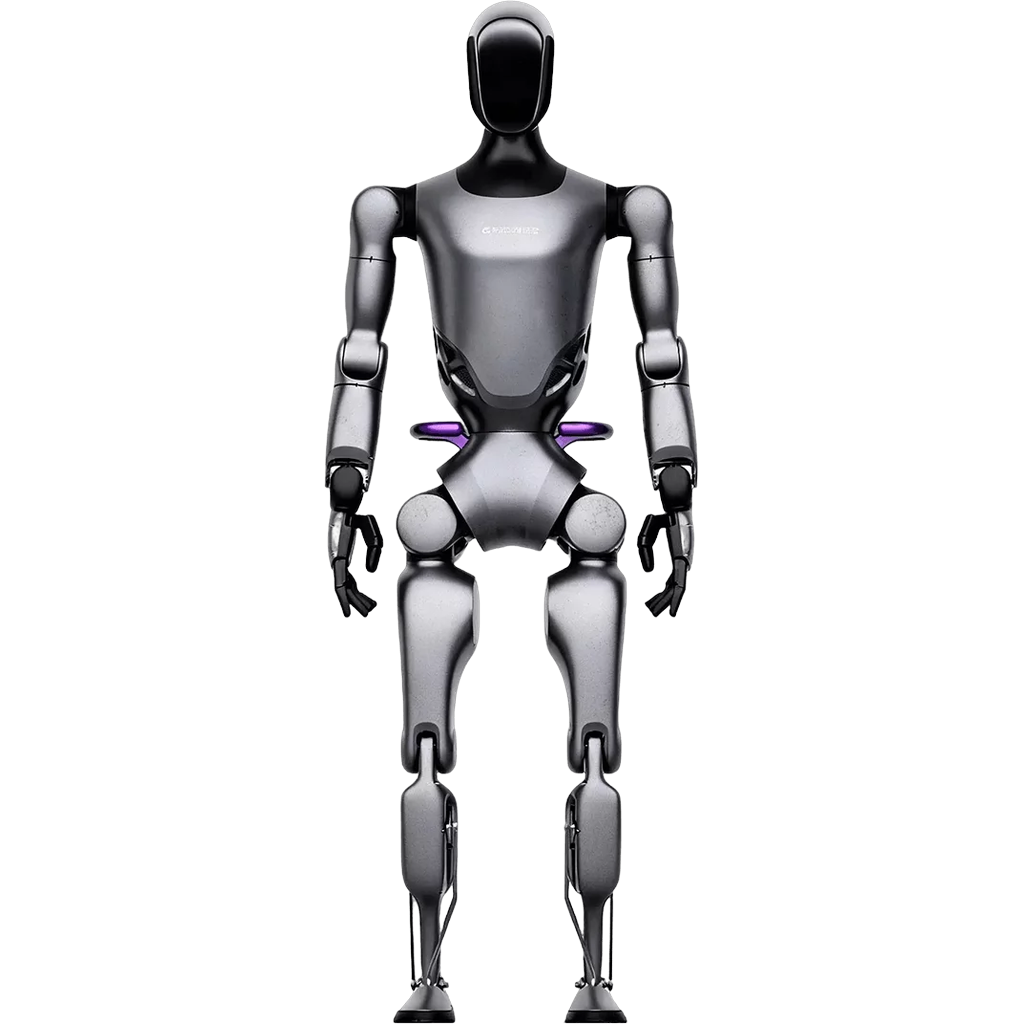
GR-2 is the second-generation general-purpose humanoid independently developed by Fourier, building on the data and technology accumulated with GR-1 to achieve comprehensive breakthroughs in hardware design, framework development and commercialisation. Whole-body degrees of freedom reach up to 53 (with an optional enhanced 12-DOF dexterous hand), maximum joint peak torque is 436 N·m, walking speed 5 km/h, single-hand load about 3 kg, and standard runtime about 2 hours with a removable battery-swap design. The dexterous hand has up to 12 degrees of freedom per hand with six array tactile sensors supporting force-controlled grasping; the platform supports NVIDIA Isaac Lab, ROS, MuJoCo, Webots and other open-source frameworks, offering more dexterous upper-body manipulation, a stronger power system and a more open development platform.
| Hardware | GR-2Not listed |
|---|---|
| Sensing | |
| Cameras | Stereo camera |
| IMU | 6-axis, supporting acceleration and angular velocity measurement |
| Computing | |
| Main processor | Intel® Core™ i7 (14 core) |
| NPU edge compute | Optional 275 TOPS compute unit |
| Actuation | |
| Full-body degrees of freedom | Up to 53 (enhanced 12-DoF dexterous hand, optional) |
| Arm degrees of freedom | 7 |
| Leg degrees of freedom | 6 |
| Dexterous-hand degrees of freedom | 6 |
| Waist degrees of freedom | 1 |
| Head degrees of freedom | 2 |
| Arm payload | approx. 3 kg |
| Arm length | 1520 mm |
| End effector | In-house dexterous hand |
| Power | |
| Battery capacity | approx. 950 Wh |
| Static runtime | approx. 2 h |
| Connectivity | |
| Expansion interfaces | Type-C, USB3.0 |
| Structure | |
| Body size | 1750 mm |
| Weight | approx. 63 kg |
| Shell material | Aluminium alloy + engineering plastic |
Fourier
Fourier