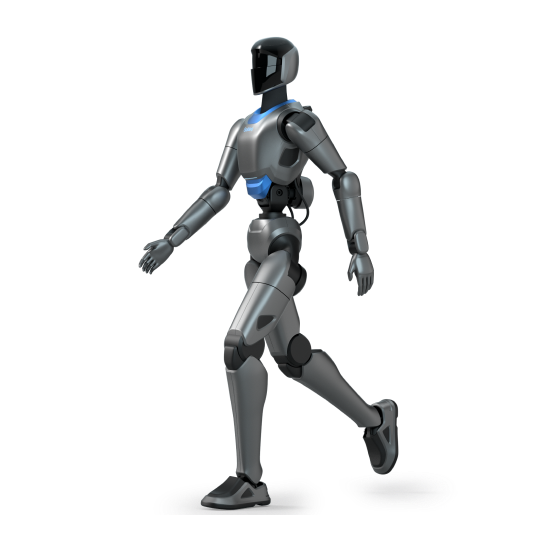
GALILEO GH-1
Galileo Tech
 Galileo Tech
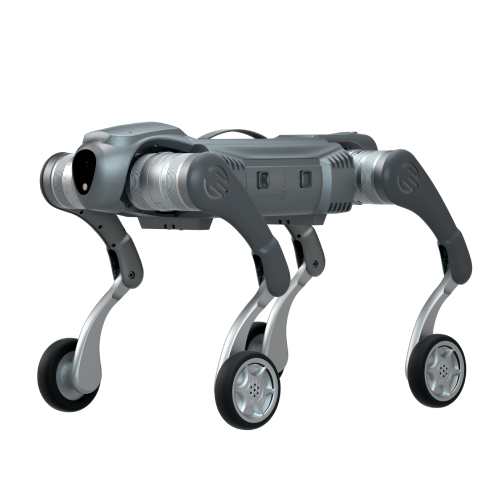
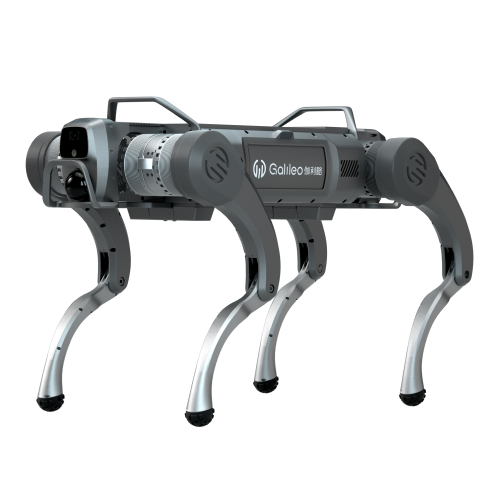
The GALILEO C1 series of intelligent bionic quadruped robots covers the C1 quadruped and the C1-W wheel-legged version, measuring 765 x 410 x 475 mm (C1) and 765 x 480 x 540 mm (C1-W) standing and weighing 22 kg (C1) and 28.5 kg (C1-W). A 20 Ah (960 Wh) 48 V lithium battery with a 100-240 V charger input supports automatic charging and low-power remote wake-up for at least 365 days; locomotion speed is adjustable from 0-3 m/s (C1) and 0-5 m/s (C1-W), with maximum slope climbing of 30 degrees or more, continuous stair climbing of 20 cm or more, 3-5 hours of runtime and 12 kg continuous payload. Control uses a domestic ARM 8-core/8-thread CPU with 8 GB RAM and 64 GB storage, with secondary development and dual-band Wi-Fi 6 supported. Joints are IP67-rated and the operating temperature range is -20 to 55 degrees C.
| Hardware | C1-WNot listed |
|---|---|
| Computing | |
| Main processor | View full specificationDomestic ARM low-power high-performance CPU (8 cores 8 threads / 8 GB RAM / 64 GB SSD) |
| Motion | |
| Max speed | 0-5 m/s (adjustable) |
| Max slope angle | ≥30° |
| Max stair height | ≥20 cm |
| Walking payload | 12 kg |
| Power | |
| Battery capacity | 20 Ah (960 Wh) |
| Walking runtime | 3-5 h |
| Static runtime | ≥365 days |
| Charging | Autonomous charging |
| Battery voltage | 48 V |
| Battery type | Lithium battery |
| Supply voltage | 48 V; 24 V (expandable as needed) |
| Connectivity | |
| Wireless | Wi-Fi 6 dual-band wireless |
| Expansion interfaces | Ethernet; USB; RS485 (interfaces expandable as needed) |
| Structure | |
| Body size | Not listed |
| Weight | 28.5 kg |
| Dimensions | 765 x 480 x 540 mm |
| Environment | |
| IP rating | IP67 |
| Operating temperature | -20°C~55°C |
Galileo Tech
Galileo Tech