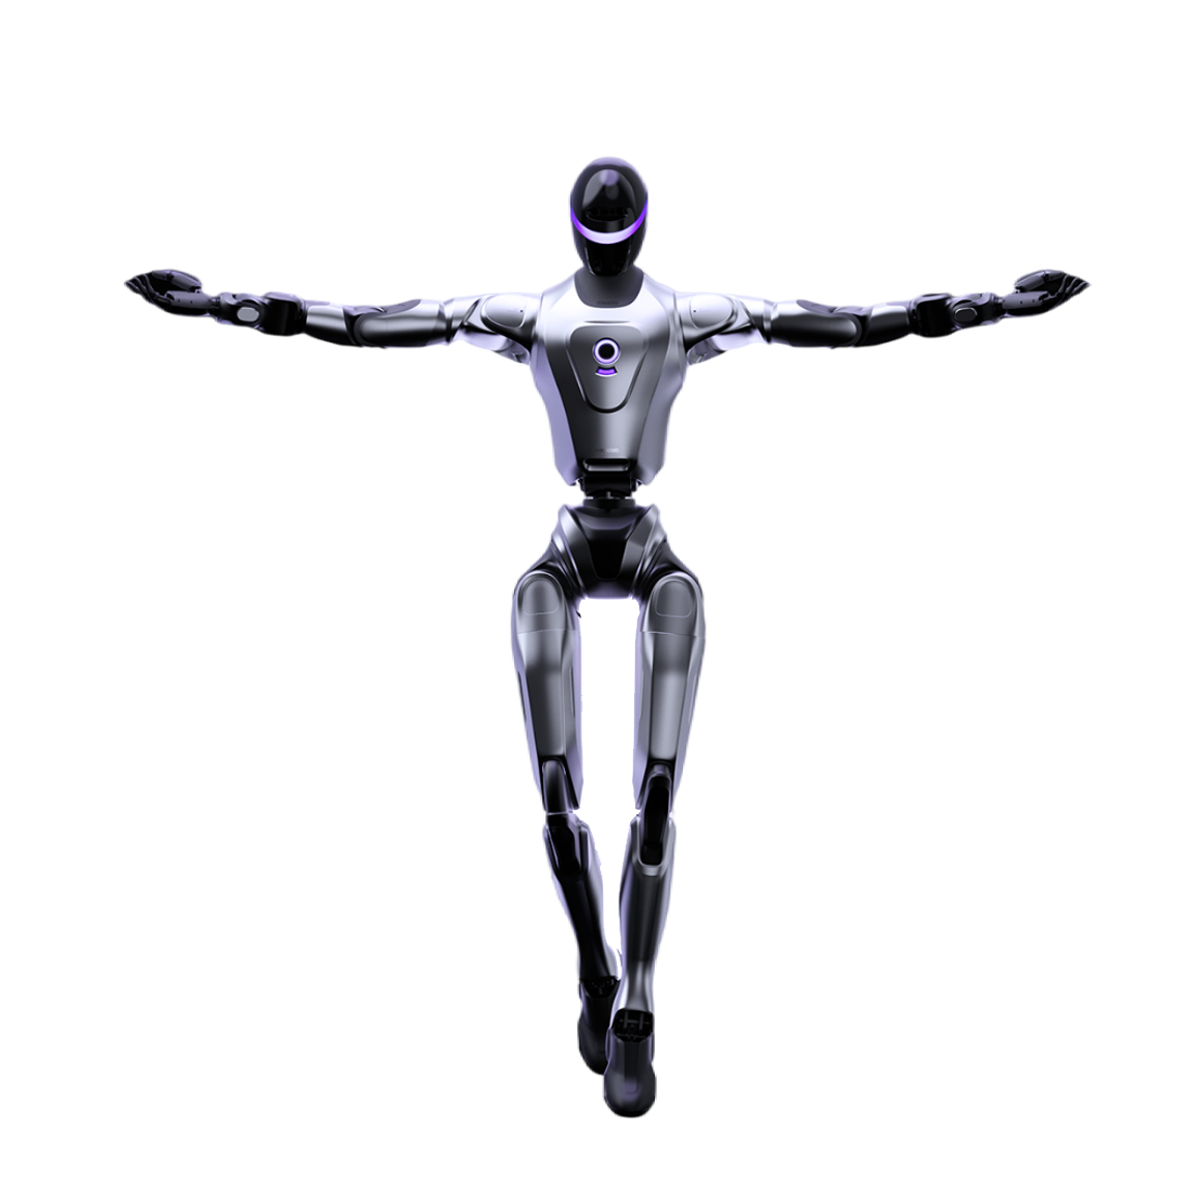
MagicBot X1
MagicLab
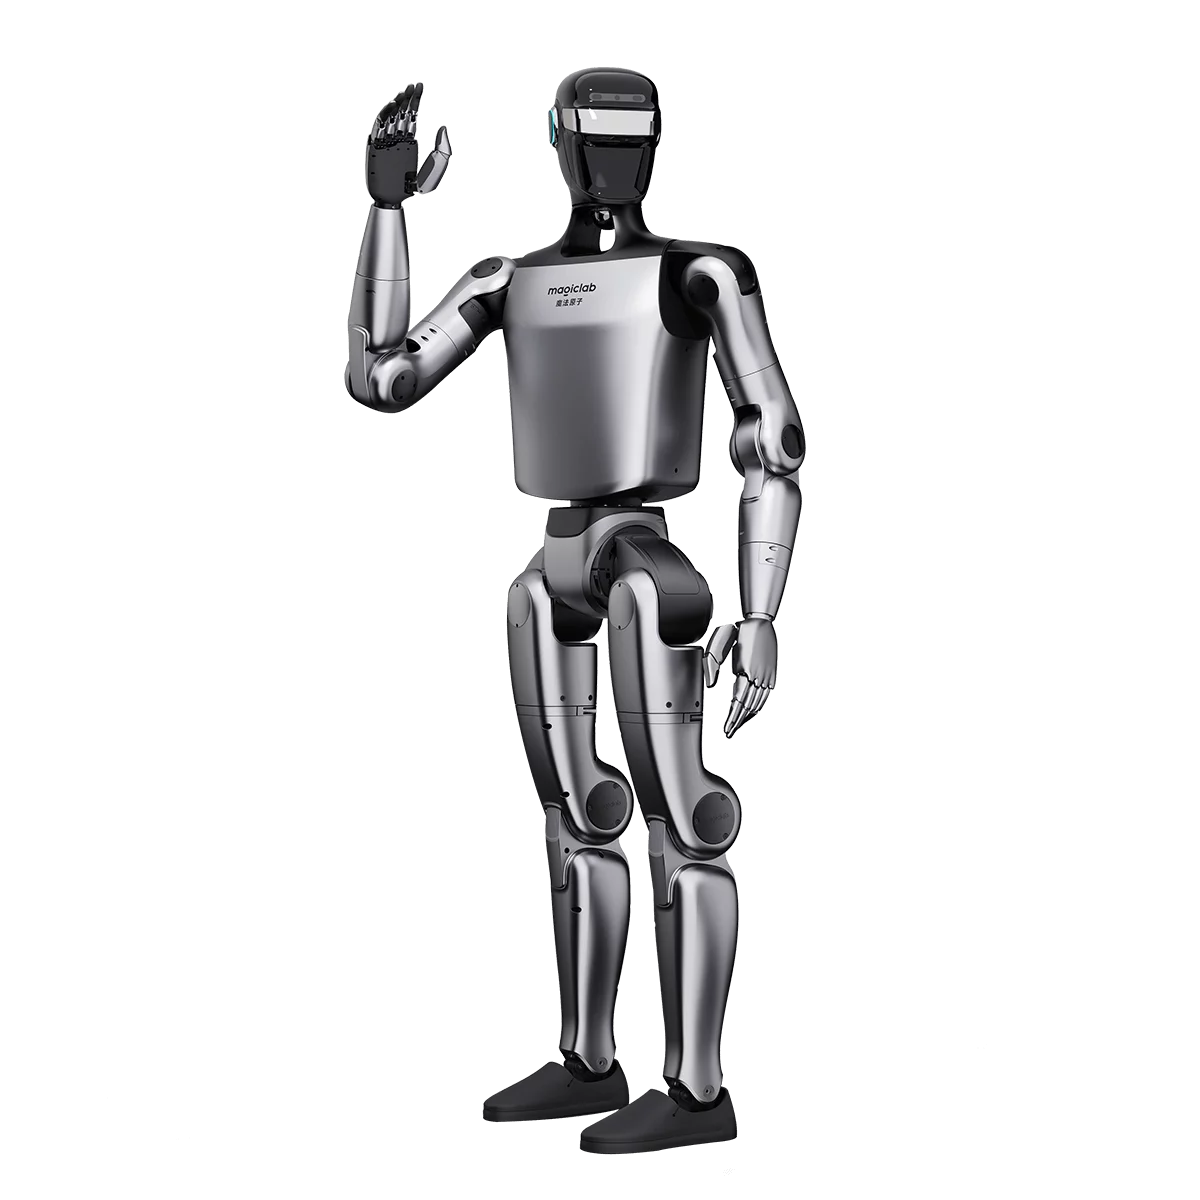
 MagicLab
MagicBot Z1 is a small-size bipedal humanoid robot for research, education and embodied AI development, built around high-dynamic performance. Joint range of motion reaches 320°, exceeding the limits of the human body, and joint torque exceeds 130 N·m on the developer edition; through imitation and reinforcement learning it masters anthropomorphic whole-body motions within one day, and has survived tens of thousands of fall tests with autonomous stand-up recovery. The robot stands about 1.37 m and weighs about 40 kg with battery, with 24 joint DoF expandable to 24-50 on the developer edition, and an optional 11-DoF tactile dexterous hand. 360° omnidirectional perception fuses multiple sensors with VLN autonomous navigation, and a VLM-based multi-modal model enables natural, proactive conversation.
| Hardware | MagicBot Z1 Developer EditionContact sales |
|---|---|
| Sensing | |
| Cameras | Depth camera + stereo fisheye cameras |
| Microphones | Microphone array |
| Speakers | 5 W speaker |
| Computing | |
| Main processor | 8-core high-performance CPU |
| Actuation | |
| Full-body degrees of freedom | 24-50 |
| Arm degrees of freedom | 5+ (2 additional wrist DoF optional) |
| Dexterous-hand degrees of freedom | Optional 11-DOF tactile dexterous hand |
| Arm payload | 3 kg |
| Arm length | approx. 0.5 m |
| End effector | Optional 11-DOF tactile dexterous hand |
| Power | |
| Battery capacity | 10000 mAh |
| Removable battery | Quick-swap |
| Static runtime | approx. 2 h |
| Charging | 62 V 5 A |
| Connectivity | |
| Wireless | Wi-Fi 6, Bluetooth 5.2 |
| Structure | |
| Body size | 1369*422*200 mm |
| Weight | approx. 40 kg+ |
MagicLab
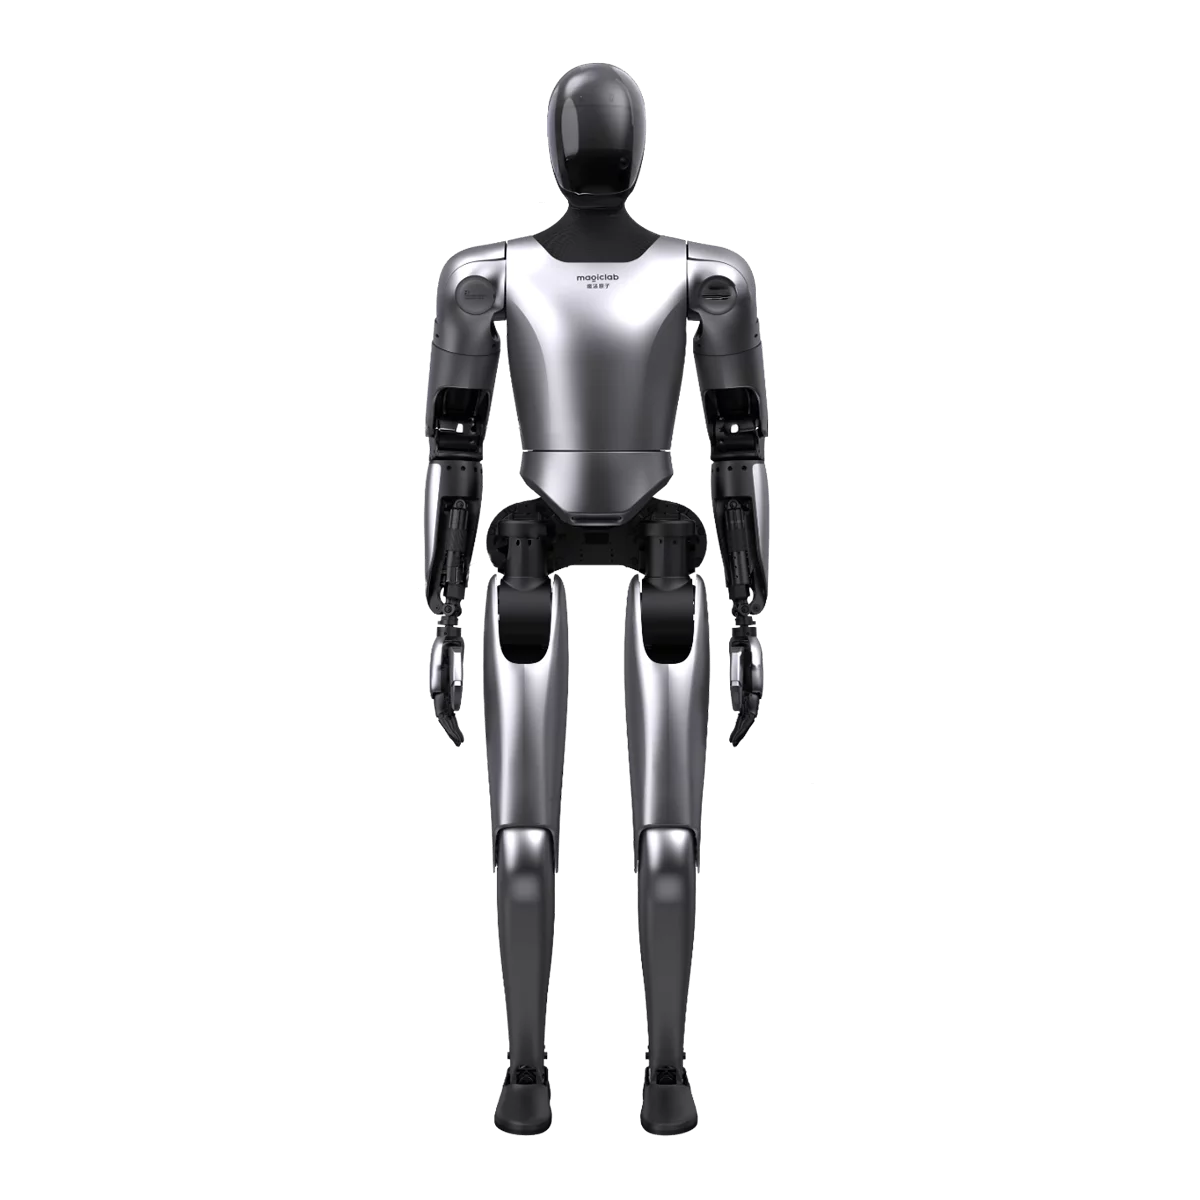
MagicLab