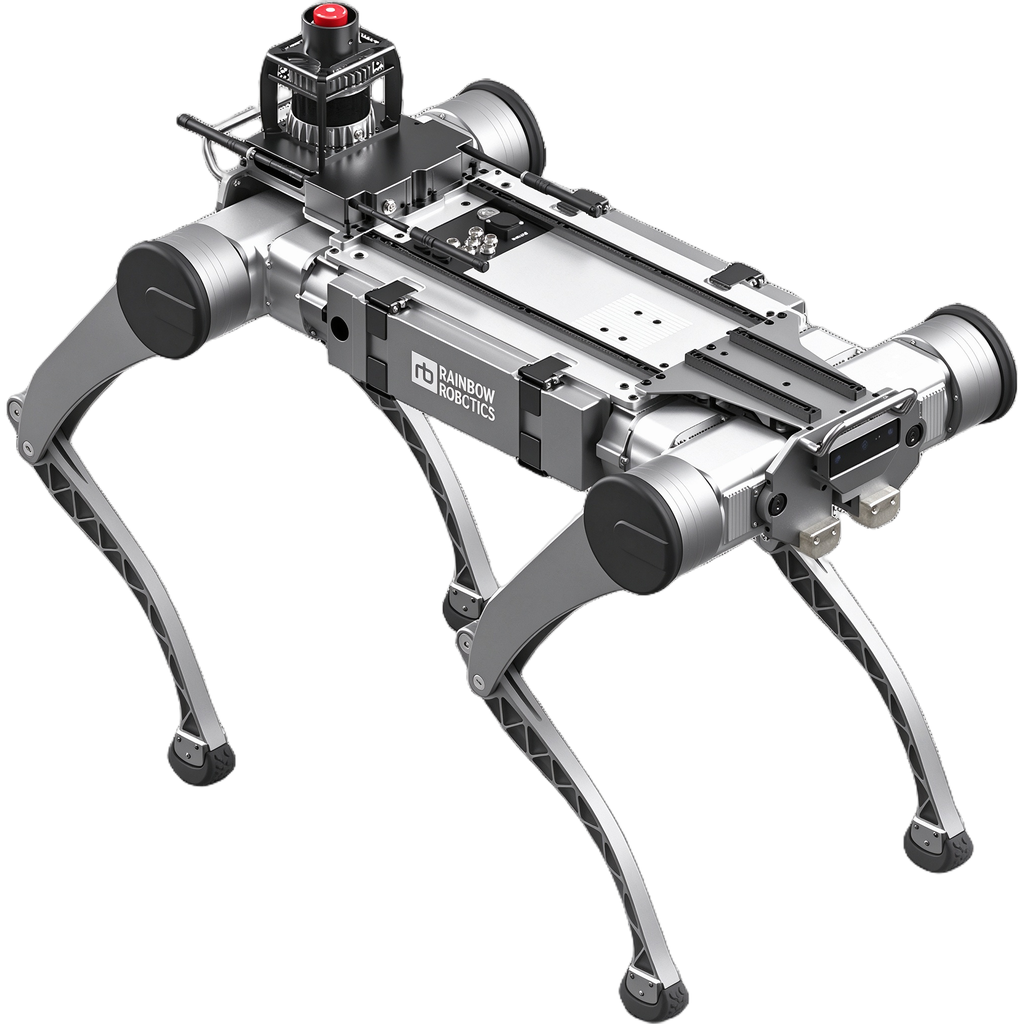
RBQ-10
Rainbow Robotics
 Rainbow Robotics
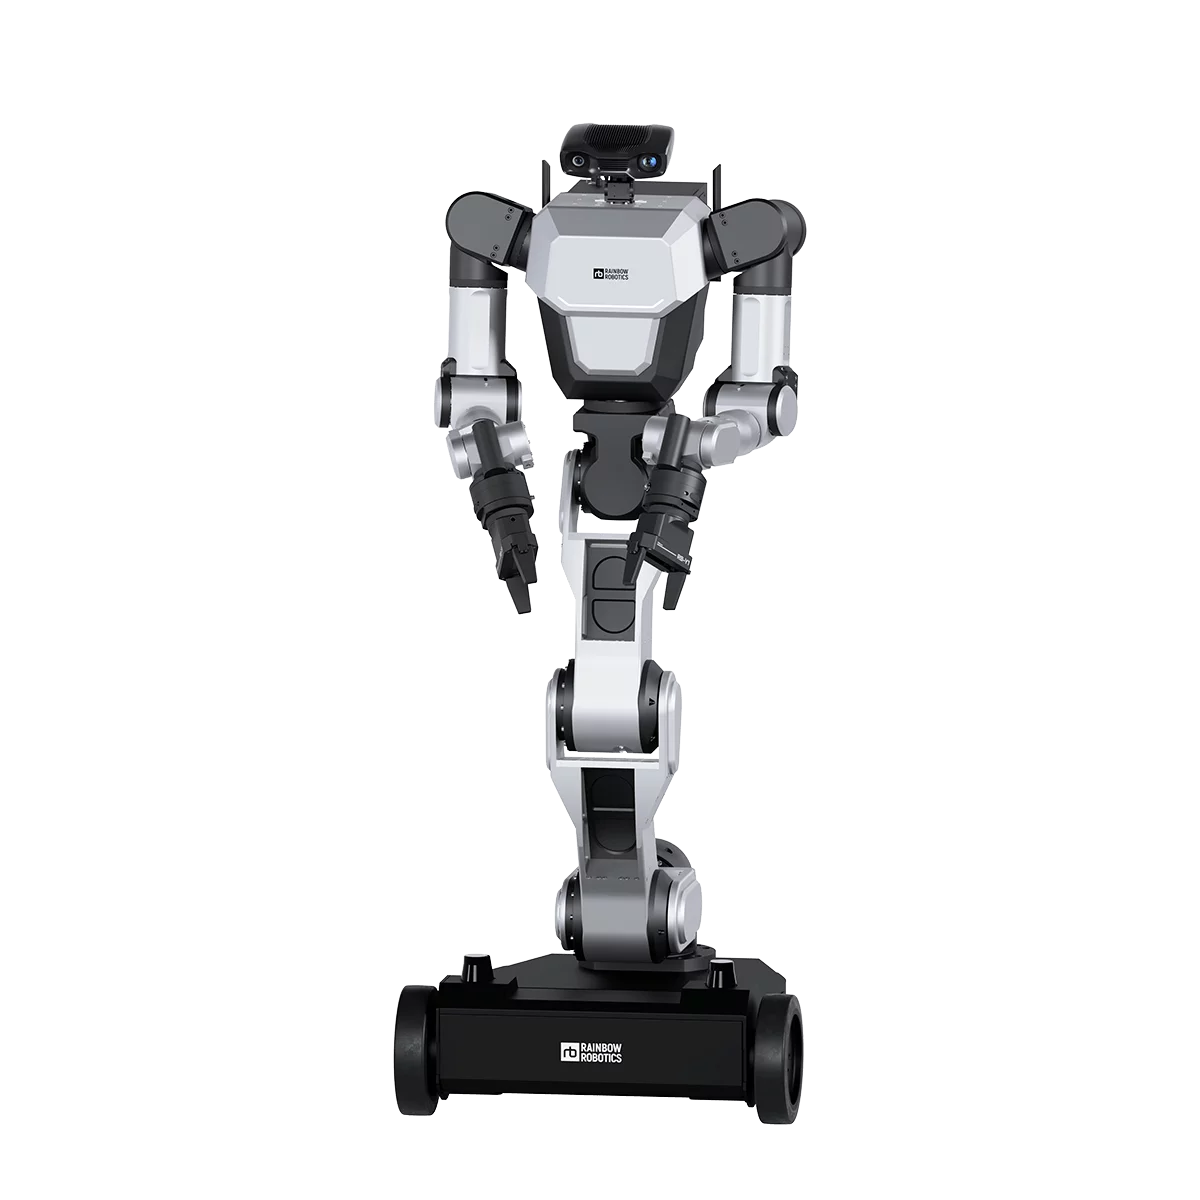
RB-Y1 is not a single-purpose end product but a humanoid-style mobile dual-arm platform for testing and validating manipulation, mobility and perception technologies in real physical environments. It treats mobility and manipulation as one: stable wheeled locomotion, dual-arm manipulation and whole-body control based on redundant DoF, with 24 DoF across the neck, both arms, the legs and the mobile base. The SDK-based open environment supports validation of optimal control, impedance control and whole-body control, and a dual-PC architecture separates real-time control from user applications on ROS 2. The research chain covers URDF, MJCF and USD simulation along with leader-follower arms and VR teaching. Single-arm payload is 3 kg, arm reach is 600 mm to the wrist plus the hand, and repeat positioning accuracy is ± 0.05 mm.
| Hardware | RB-Y1Contact sales |
|---|---|
| Actuation | |
| Full-body degrees of freedom | 20 DOF 26 DOF |
| Arm degrees of freedom | 7 DOF x 2 7 DOF x 2 |
| Leg degrees of freedom | 6 DOF 6 DOF |
| Head degrees of freedom | 2 DOF 2 DOF |
| Arm payload | 3 kg per arm |
| Arm length | 600 mm (to the wrist) plus hand |
| Power | |
| Battery capacity | 50 V, 25 Ah (1250 Wh) |
| Structure | |
| Body size | 1400 mm |
| Weight | 131 kg |
| Shell material | Aluminium alloy |
Rainbow Robotics