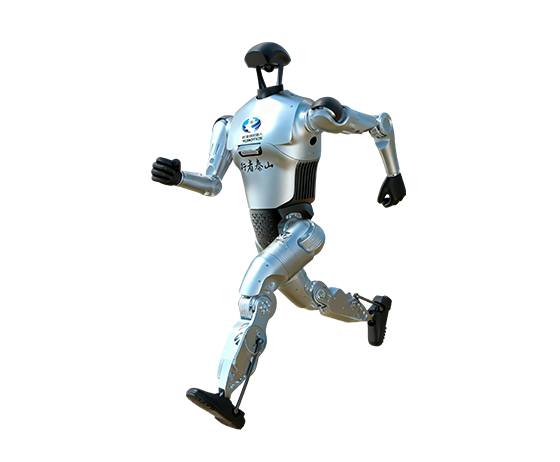
Humanoid Robot E1
YOBOTICS
 YOBOTICS
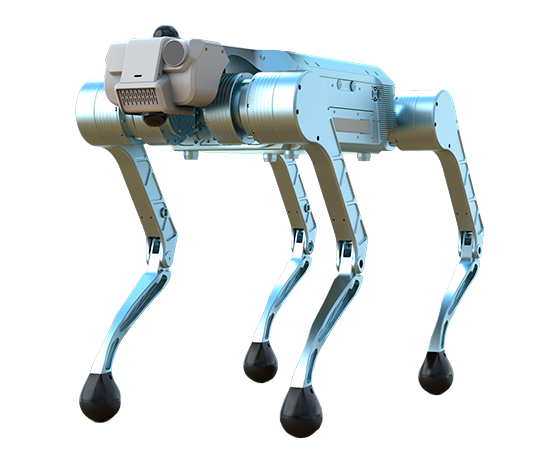
Y20 is an all-terrain quadruped built for autonomous navigation and inspection: 910 x 420 x 534 mm, about 38 kg, 12 degrees of freedom in the legs, driven by brushless DC motors with knee linkage transmission and hard-wearing rubber foot pads. Maximum walking speed is 2 m/s and running speed 4 m/s; it climbs 35 degree ground slopes, 25 cm stairs and surmounts 36 cm vertical obstacles, with a maximum dynamic payload of 37 kg and 2 hours of composite-motion runtime. The fully modular design keeps after-sales maintenance costs low, and the open SDK simplifies secondary development for education, research, security inspection and related applications.
| Hardware | Y20Contact sales |
|---|---|
| Actuation | |
| Leg degrees of freedom | 12 |
| Joint motors | Brushless DC motor |
| Motion | |
| Max speed | 4 m/s |
| Max running speed | 4 m/s |
| Max slope angle | 35° |
| Max step height | 36 cm |
| Max stair height | 25 cm |
| Max payload | 37 kg |
| Walking payload | 37 kg |
| Power | |
| Walking runtime | 2 h composite-motion endurance |
| Structure | |
| Body size | 534 mm |
| Weight | approx. 38 kg |
| Dimensions | 910 x 420 x 534 mm |
| Shell material | Aluminium alloy + rubber |
YOBOTICS
YOBOTICS