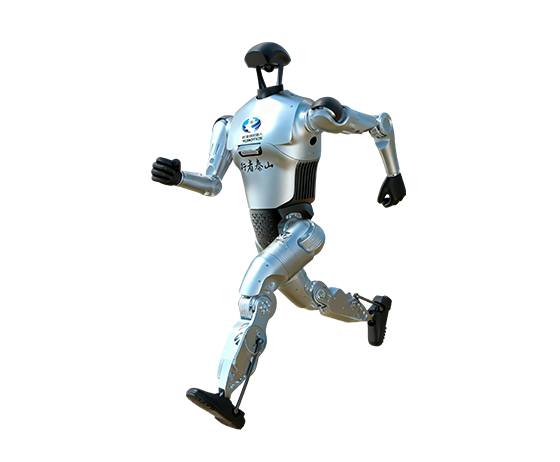
Humanoid Robot E1
YOBOTICS
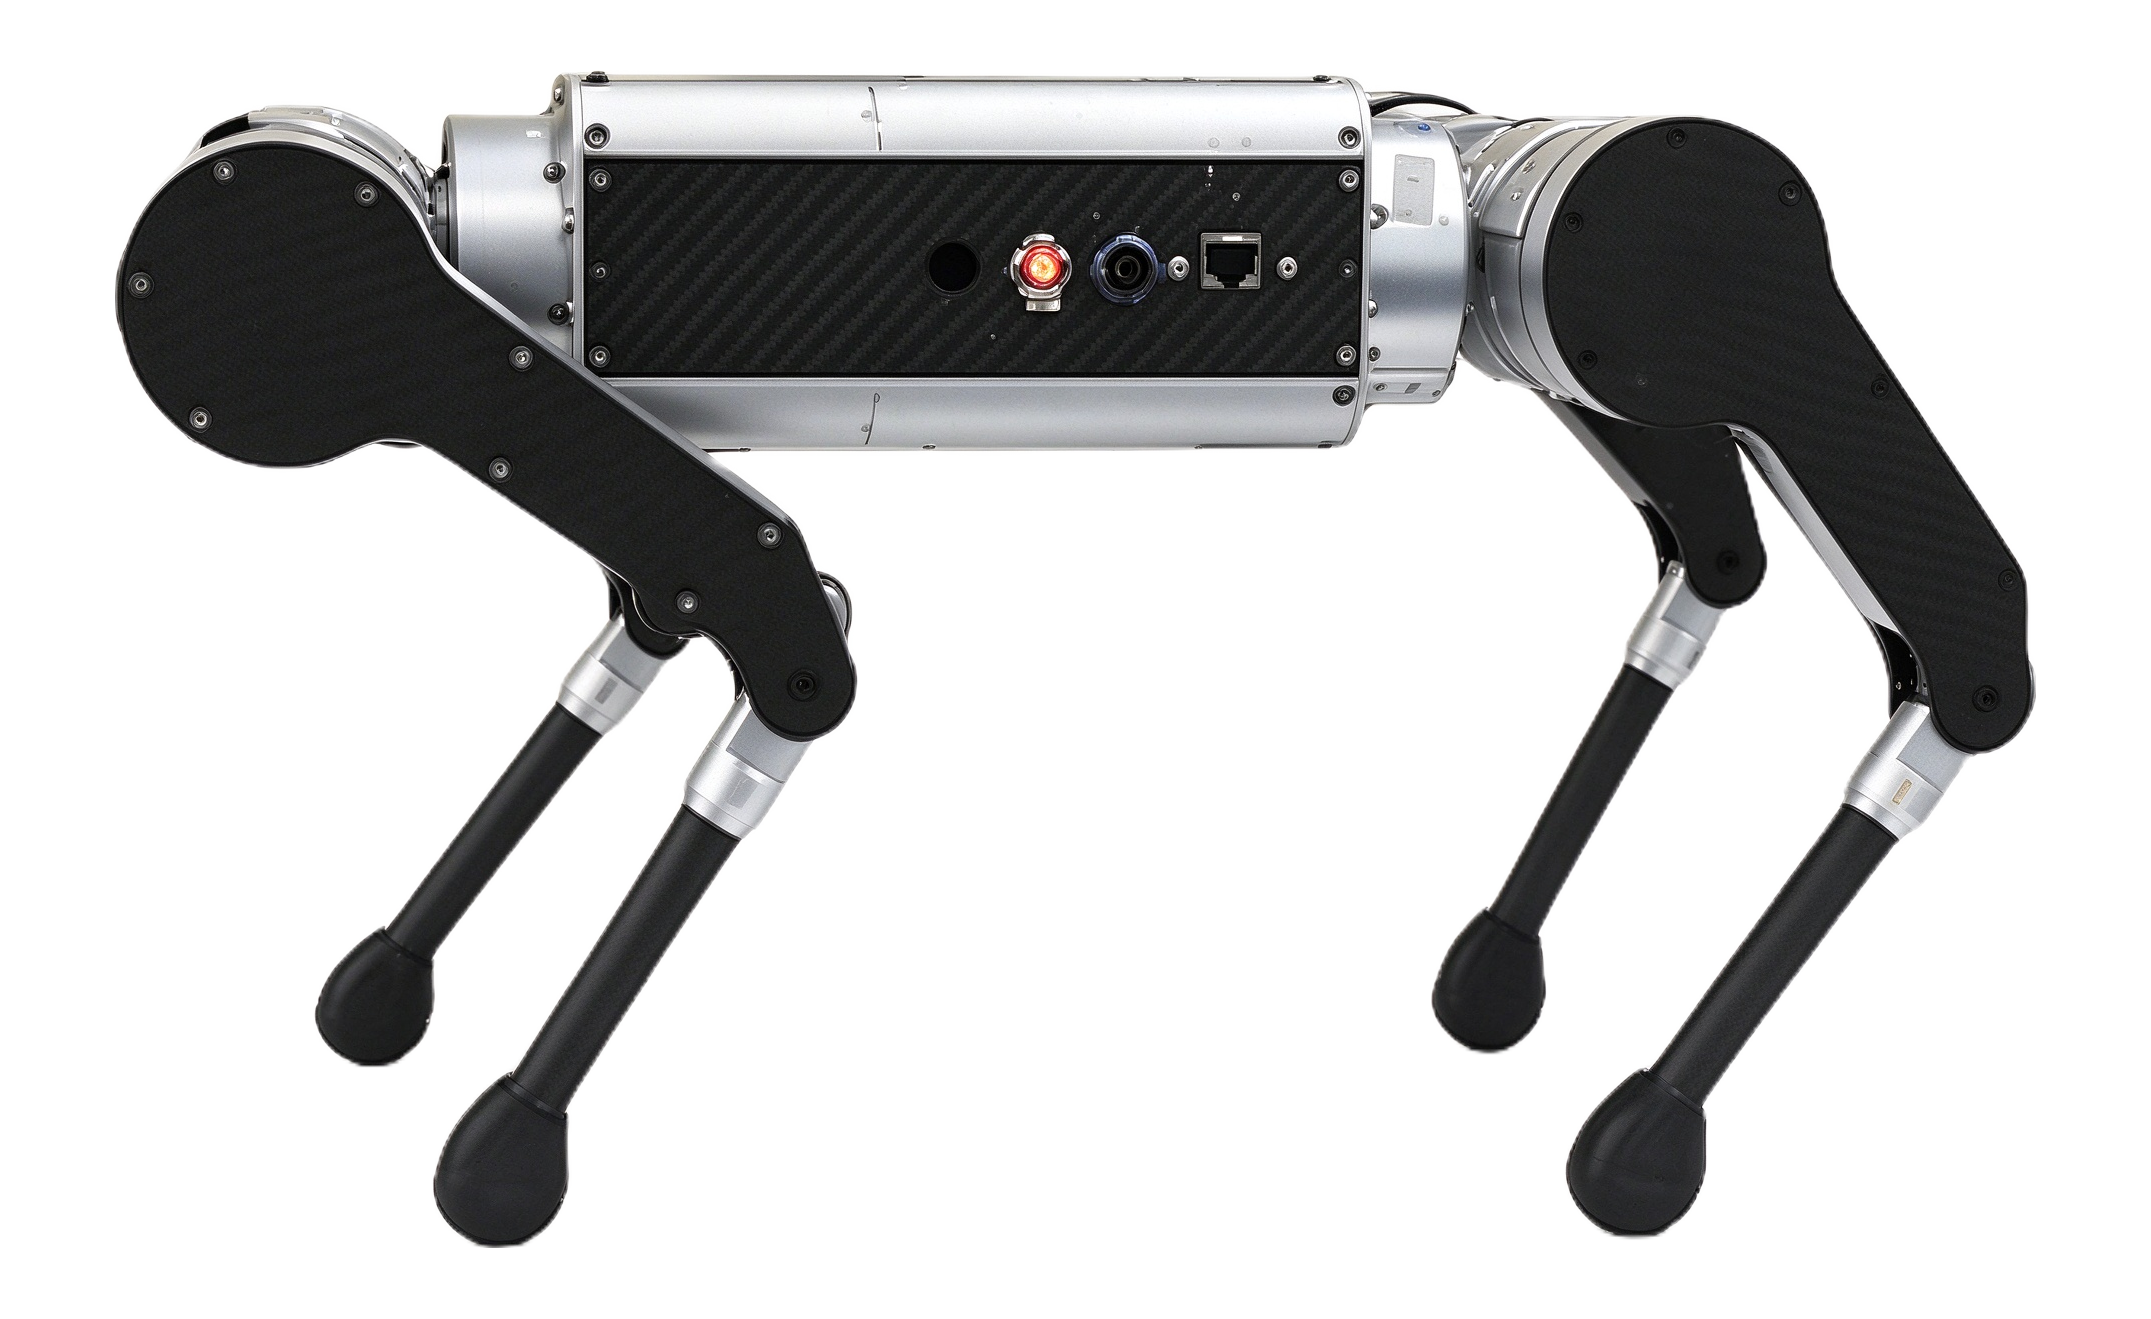
 YOBOTICS
Y5 is a desktop-class quadruped with high dynamic performance, combining strong drive capability with advanced motion control algorithms. A flagship product for education and research quadrupeds, it offers rich secondary development interfaces (USB, Ethernet, serial and CAN). The machine weighs about 5.6 kg including the battery, measuring about 455 x 227 x 280 mm standing and about 450 x 227 x 173 mm folded for easy desktop placement and portability. Twelve degrees of freedom overall (3 per leg) support slow walking, fast walking and trotting gaits, with dynamic balance and fall recovery; unloaded running speed is about 1.4 m/s, continuous walking payload over 3 kg, and runtime about 110 minutes. It runs Ubuntu 16.04 on an Upboard (Intel Atom x5-Z8350) main controller, for teaching, research, algorithm validation and secondary development.
| Hardware | Y5Contact sales |
|---|---|
| Computing | |
| Main processor | Upboard, Intel Atom x 5-Z8350 @1.92 GHz, 2 x 32 GB |
| Actuation | |
| Full-body degrees of freedom | 12 across the whole unit |
| Leg degrees of freedom | 3 per leg |
| Motion | |
| Max running speed | 1.4 m/s (unloaded) |
| Walking payload | >3 kg |
| Power | |
| Walking runtime | approx. 110 min |
| Supply voltage | Output 29.4 V, 3 A max |
| Connectivity | |
| Expansion interfaces | USB, Ethernet, serial port, CAN |
| Structure | |
| Weight | Approx. 5.6 kg ± 0.5 kg (including battery) |
| Dimensions | approx. 455 mm x 227 mm x 280 mm |
| Folded dimensions | approx. 450 mm x 227 mm x 173 mm |
YOBOTICS
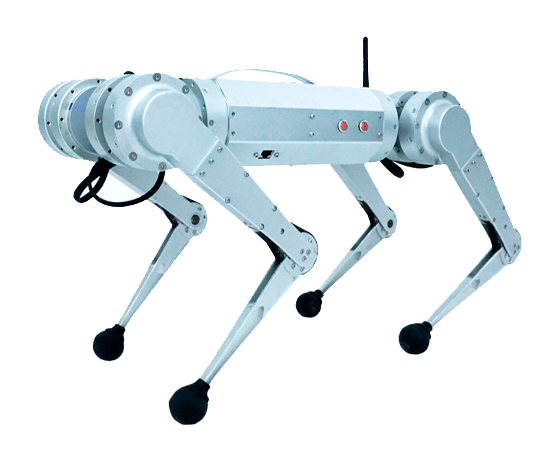
YOBOTICS