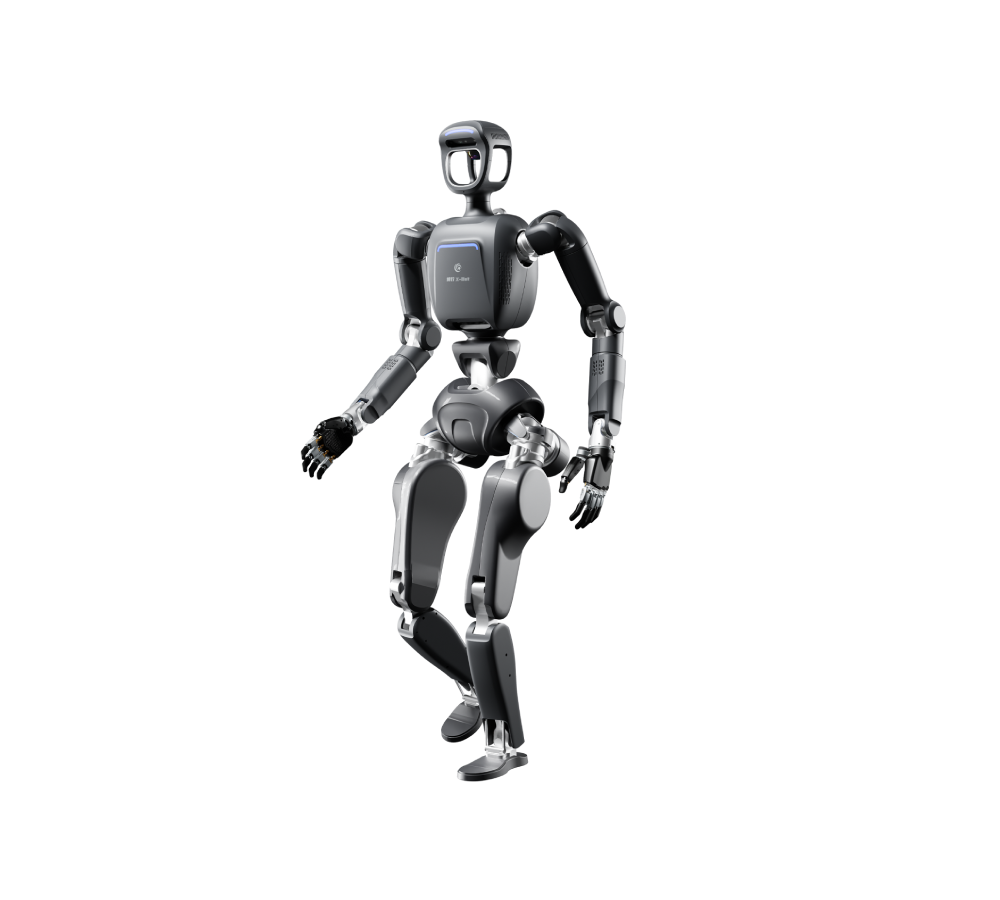
Boxing X-Bot
YQBionics
 YQBionics
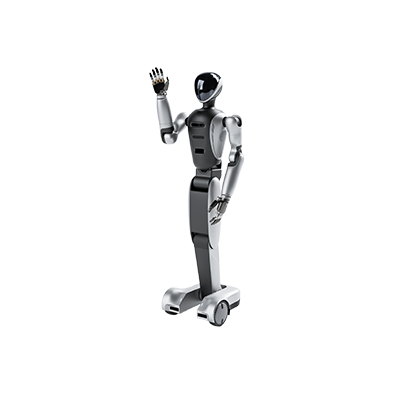
Bowen W-Bot 2.0 is a wheeled humanoid using a human-like hip-knee-ankle triple-folding design on a wheeled chassis, with 43 degrees of freedom across the body: 7 DoF in the torso (hip, knee and ankle plus chassis x 2) and 7 DoF per arm; overall height is 1.78 m and weight 60 kg. Knee joint limit torque is about 360 N·m, single-arm payload 10 kg and maximum walking speed 3 m/s. It can be paired with the X-Hand M1 or Y-Hand M1 dexterous hands, with D435i/D455 depth cameras and a 360 degree radar; locomotion control uses dual main control platforms (two Jetson Orin NX 16 GB, up to 314 TOPS) with hierarchical whole-body neural-network balance control, and battery capacity is 2400 Wh.
| Hardware | Bowen W-Bot 2.0Not listed |
|---|---|
| Sensing | |
| Cameras | Intel RealSense D435i & D455 depth cameras + Livox 360 LiDAR |
| Computing | |
| NPU edge compute | Dual NVIDIA Jetson Orin NX 16GB embedded computers |
| Actuation | |
| Full-body degrees of freedom | 43 DoF |
| Arm degrees of freedom | Shoulder ×3 + elbow ×1 + forearm joint ×1 + wrist ×2 = 7 |
| Dexterous-hand degrees of freedom | Compatible with X-Hand M1 or Y-Hand M1 dexterous hand |
| Arm payload | 10 kg (with six-axis force/torque sensor) |
| Power | |
| Battery capacity | View full specificationBattery capacity 2400 Wh, max. voltage 48 V, max. output current 30 A |
| Connectivity | |
| Wireless | CAN bus |
| Structure | |
| Body size | 1.78 m |
| Weight | 60 kg |
YQBionics