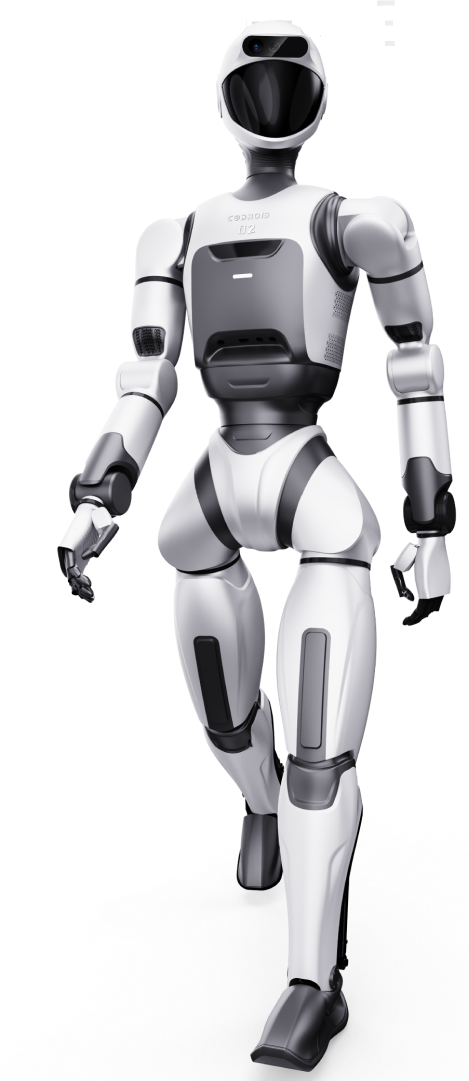
CODROID 02
ESTUN CODROID
 ESTUN CODROID
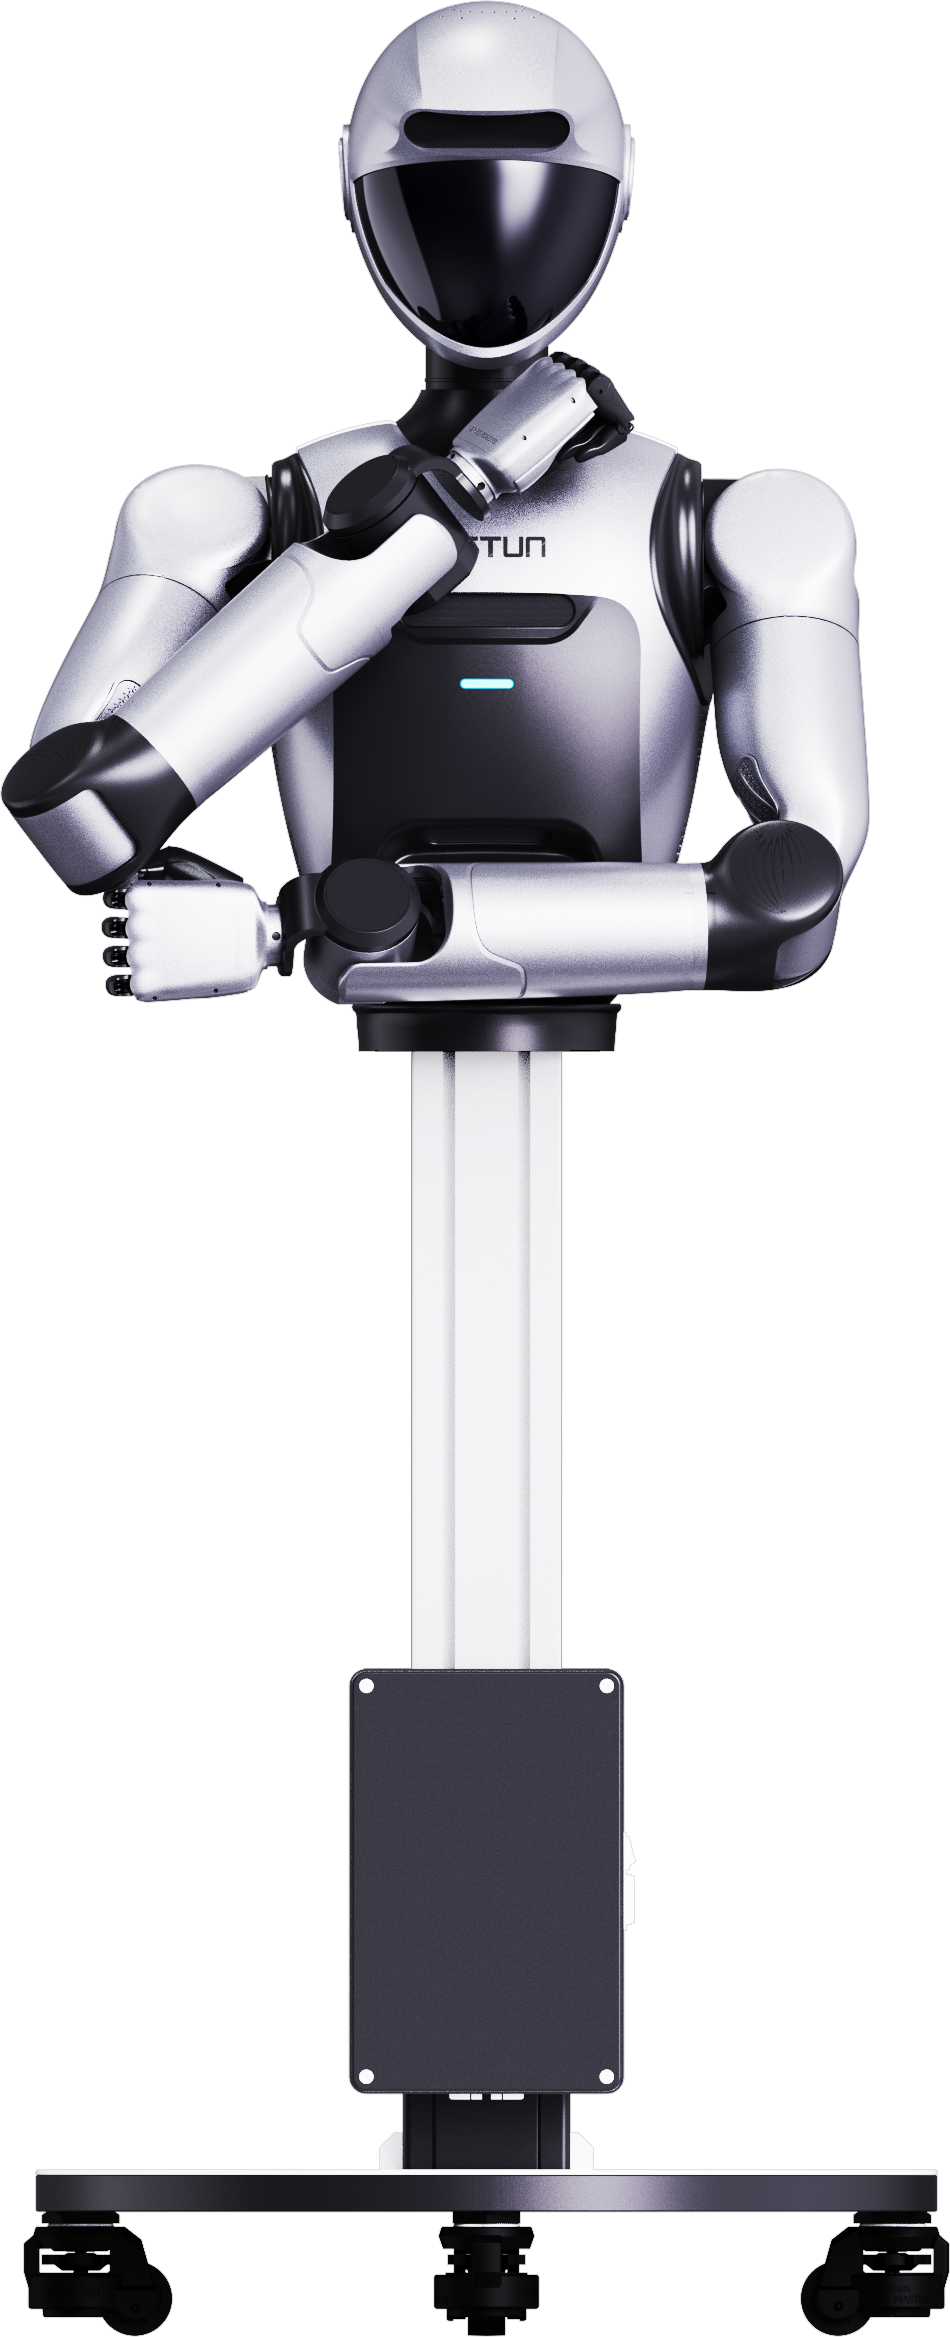
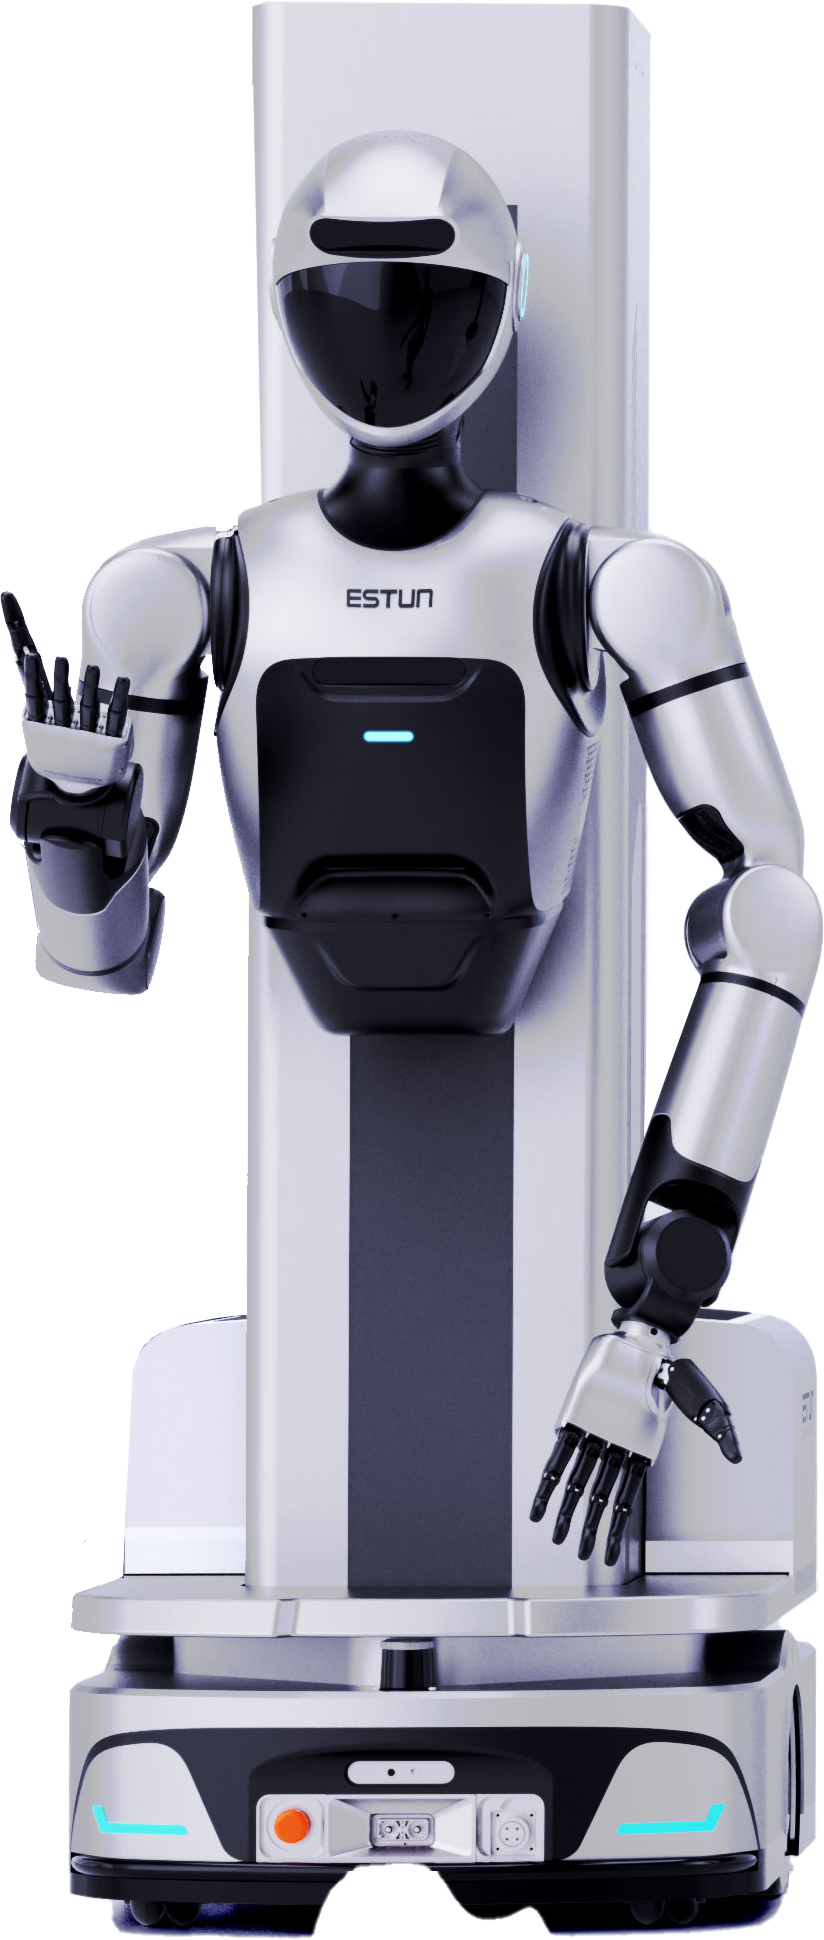
The Enlightenment C05-U dexterous adaptation robot has a head-to-ground height manually adjustable from 138 to 168 cm, weighs 32 kg (excluding the base) and has a 550 mm arm reach. Each arm has 7 rotary-joint degrees of freedom with a 5 kg payload (excluding the dexterous hand) and weighs no more than 8.5 kg; a dexterous hand is optional (mounting flange provided, DC 24 V / 2.5 A, RS-485). The head weighs about 2 kg with manual pitch adjustment from about -25 to 10 degrees, and voice modules, a ToF head camera and rotary joints (pitch/steering) are optional. The body uses a metal and industrial plastic shell with 3 Ethernet ports, 1 HDMI, 2 USB 3.0 ports and an emergency stop interface, with internal air-duct cooling; lower-body height is manually adjustable by about 300 mm and external modules can be attached. The base is a mobile structure with optional counterweight and high stability when locked. Power is 220 V / 10 A with 1500 W peak power, communication over EtherCAT/UDP, harmonic drives and open EtherCAT slave configuration.
| Hardware | CODROID Enlightenment C05-UNot listed |
|---|---|
| Sensing | |
| Cameras | ToF headcamera |
| Microphones | Voice module |
| Actuation | |
| Arm degrees of freedom | 7 rotary-joint DoF |
| Head degrees of freedom | Rotary joints (pitch / steering) |
| Arm payload | 5 kg (excluding dexterous hand) |
| Arm length | R550 mm |
| End effector | View full specificationDexterous hand optional, mounting flange provided, DC 24 V / 2.5 A, RS-485 |
| Connectivity | |
| Expansion interfaces | View full specificationEthernet x 3, HDMI x 1, USB 3.0 x 2, emergency stop x 1, 30 mm feedthrough x 1 |
| Structure | |
| Body size | 138~168 cm |
| Weight | 32 kg (excluding the base) |
| Shell material | Metal (arms); metal / industrial plastic (body) |
ESTUN CODROID
ESTUN CODROID