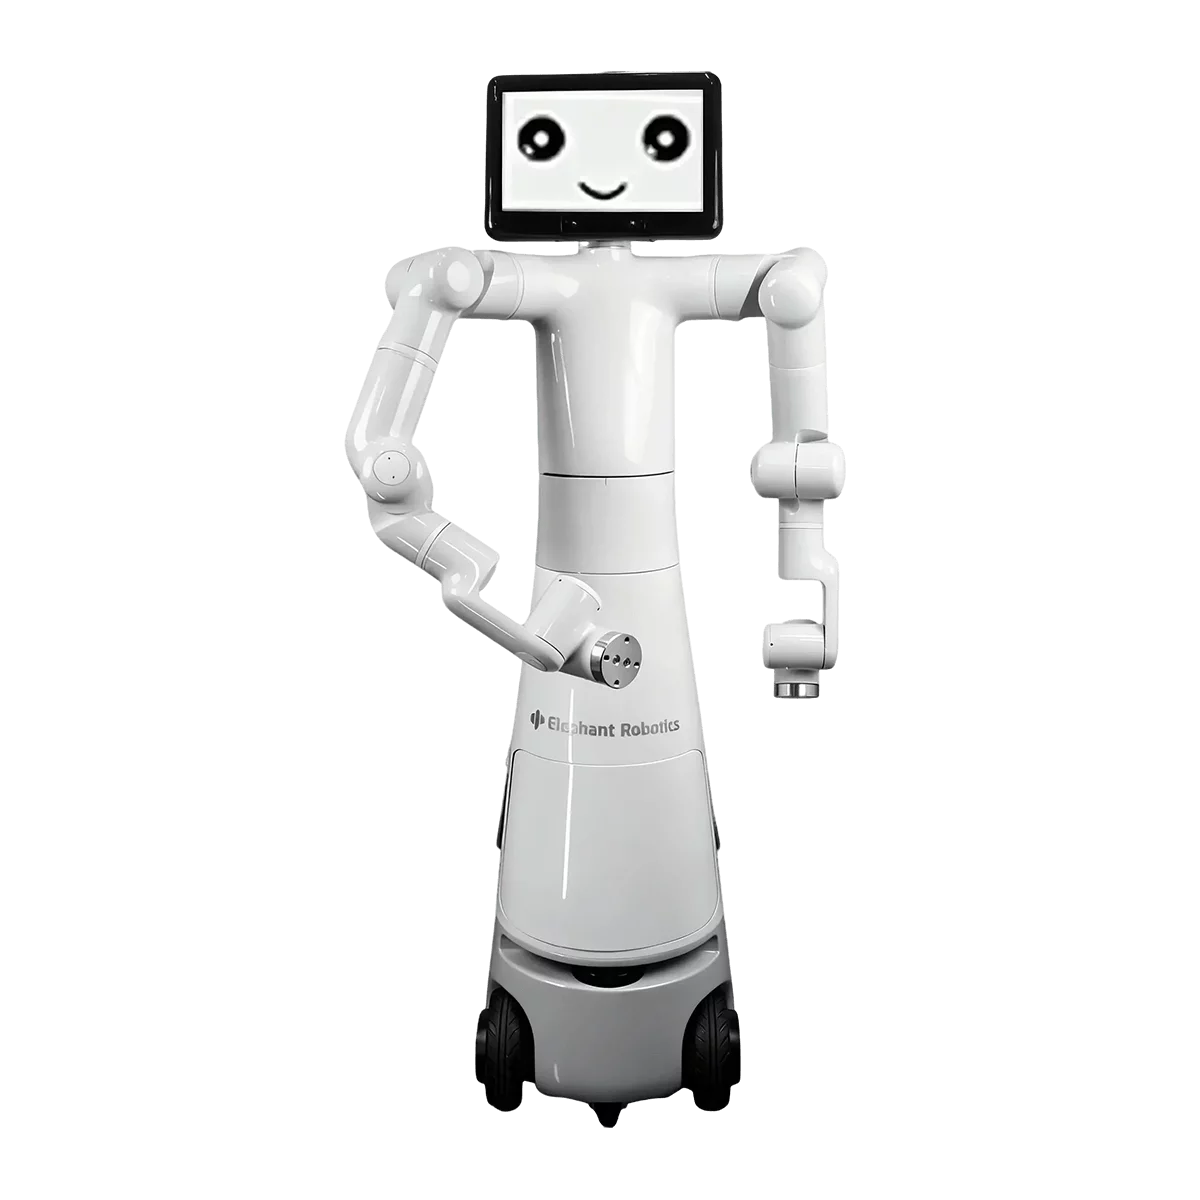
Mercury X1
Elephant Robotics
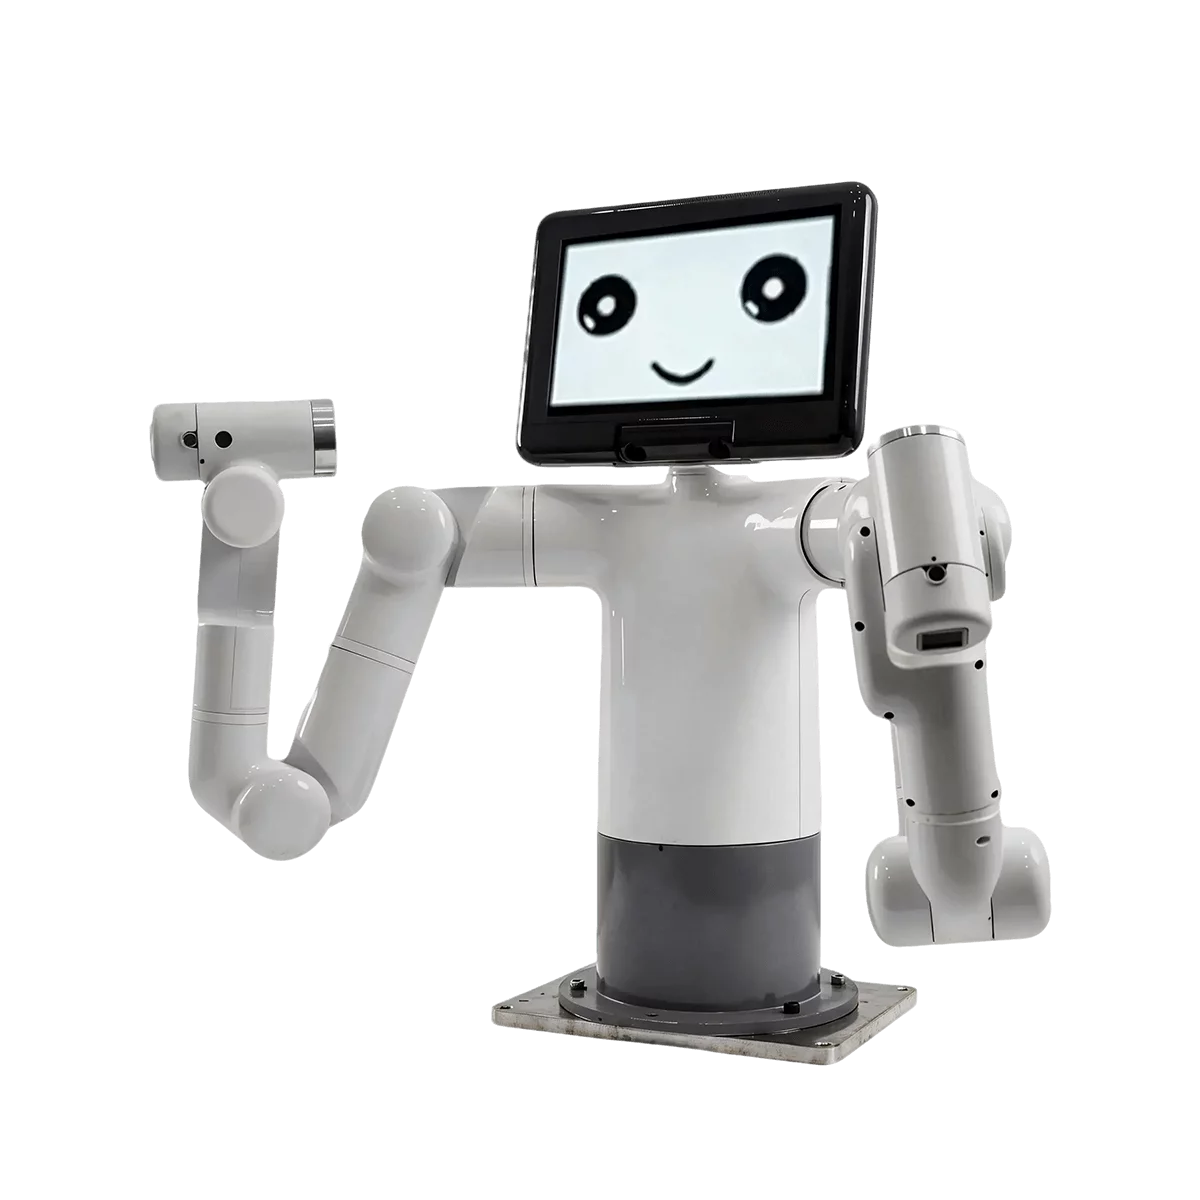
 Elephant Robotics
Mercury B1 is a dual 7-axis semi-humanoid robot with two 7-DOF arms giving 17 degrees of freedom, a net weight of 8 kg and dimensions of 200 x 192.5 x 537 mm; maximum working radius is 450 mm, single-arm payload 1 kg and repeat positioning accuracy +/-0.05 mm. Harmonic drives and electromagnetic friction-plate joint brakes are used, with a body of carbon fibre, aluminium alloy and engineering plastic, a 67 TOPS main controller, a 9-inch touchscreen and an Orbbec Deeyea 3D camera. An open-source software ecosystem supports dual-arm coordination, seven intelligent algorithms and exoskeleton teleoperation for education, research and embodied AI data collection.
| Hardware | Mercury B1Contact sales |
|---|---|
| Sensing | |
| Cameras | Orbbec Deeyea |
| Microphones | Linear 4-mic array, 5 m 180 degree pickup |
| Computing | |
| NPU edge compute | 67 TOPS |
| Actuation | |
| Full-body degrees of freedom | 17 DoF |
| Arm payload | 1 kg |
| Connectivity | |
| Wireless | Wi-Fi / Bluetooth |
| Expansion interfaces | CAN bus / Ethernet / USB / serial port |
| Structure | |
| Body size | 537 mm |
| Weight | 8 kg |
| Shell material | Carbon fibre, aluminium alloy, engineering plastic |
Elephant Robotics
Elephant Robotics