Mercury B1
Elephant Robotics
 Elephant Robotics
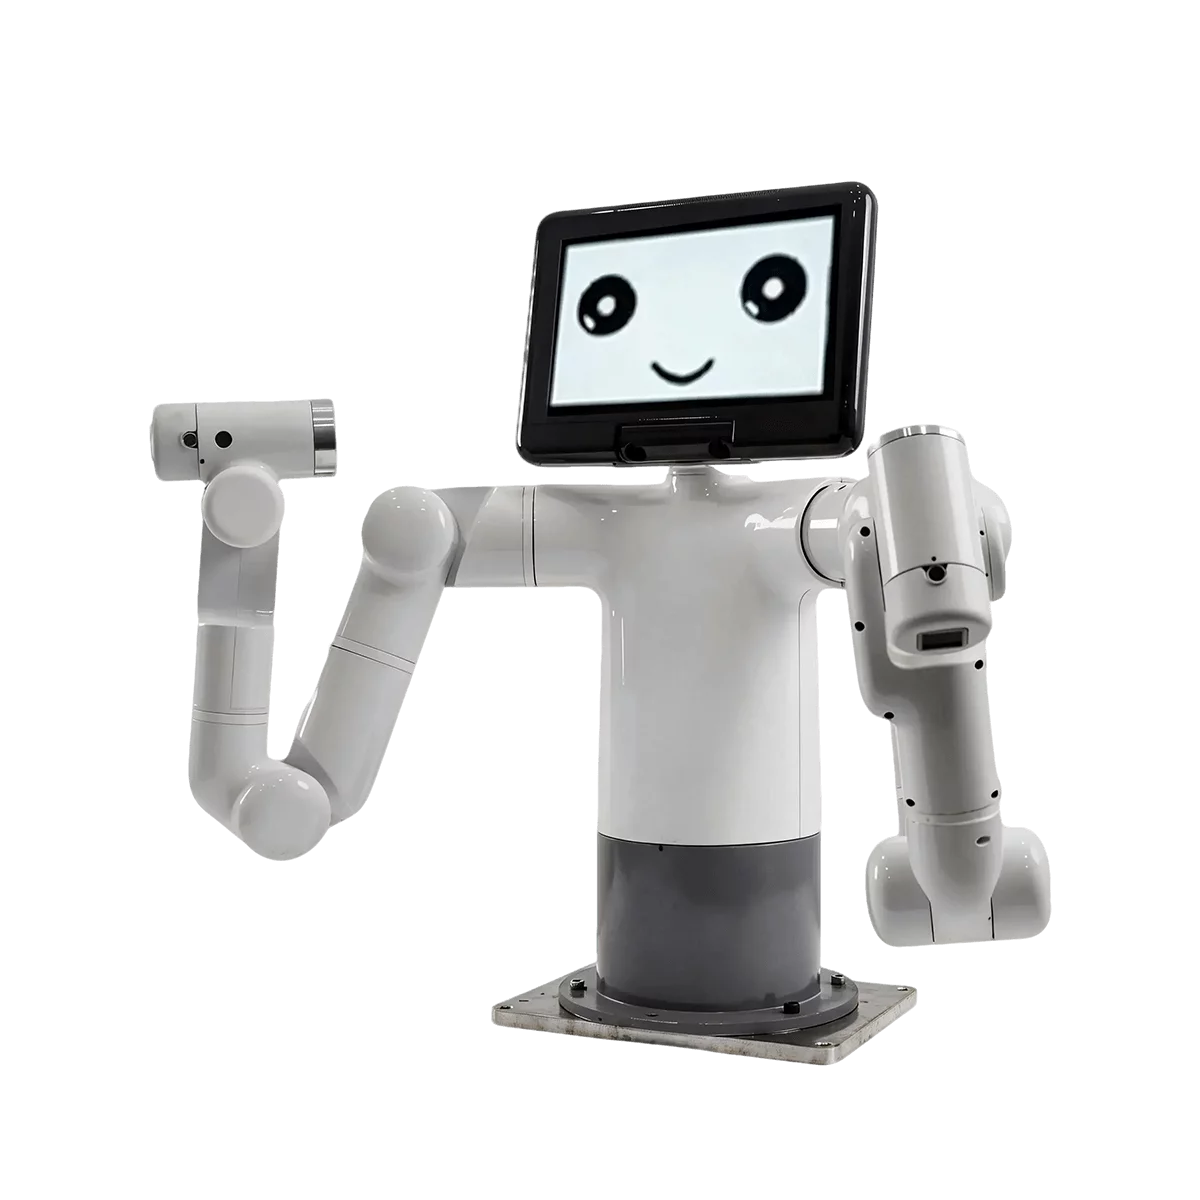
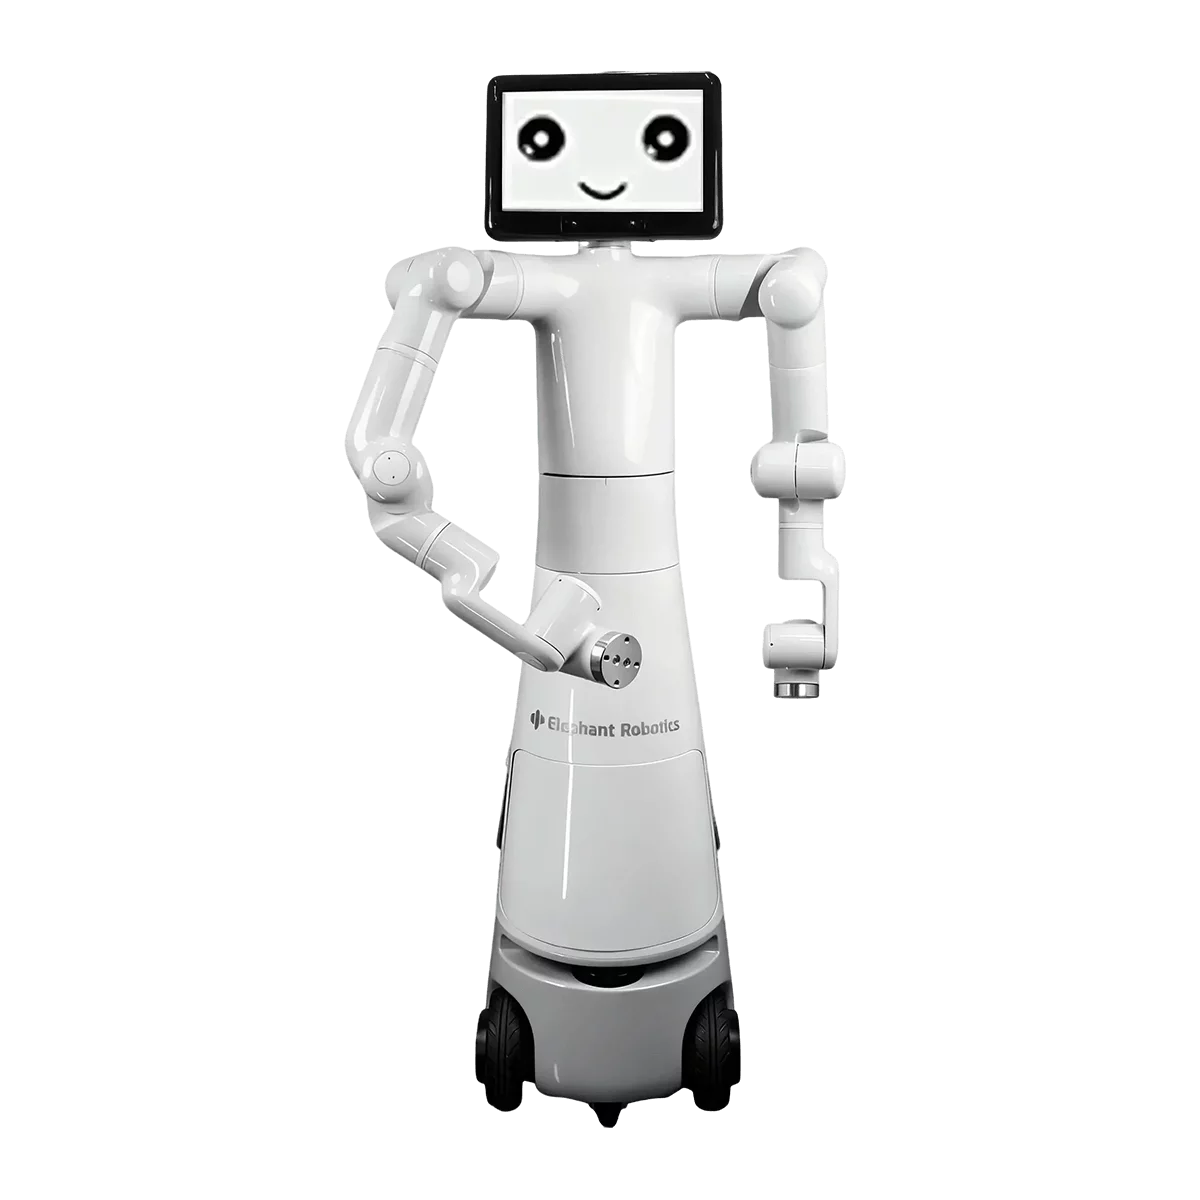
Mercury X1 is a general-purpose wheeled full humanoid 1.18 m tall with a net weight of 55 kg and 19 degrees of freedom, built from a dual 7-axis arm system on a high-performance wheeled mobile chassis; maximum speed is 1.2 m/s and maximum climbing angle 15 degrees. Control is handled by a Jetson Orin Nano SUPER (8 GB, 67 TOPS), with a 9-inch touchscreen, LiDAR/ultrasonic/2D vision navigation and an Orbbec Deeyea 3D camera; runtime is about 8 hours and arm payload 1 kg. An open-source software ecosystem with Python/C++ APIs and exoskeleton teleoperation supports education and research, embodied AI data collection and service scenarios.
| Hardware | Mercury X1Contact sales |
|---|---|
| Sensing | |
| Cameras | Orbbec Deeyea |
| Microphones | Linear 4-mic array, 5 m 180 degree pickup |
| Computing | |
| Main processor | Jetson Orin Nano SUPER 8 GB |
| NPU edge compute | 67 TOPS |
| Actuation | |
| Full-body degrees of freedom | 19 DoF |
| Arm payload | 1 kg |
| Power | |
| Static runtime | 8 h |
| Connectivity | |
| Wireless | CAN bus / Wi-Fi / Ethernet / Bluetooth / USB / serial port |
| Structure | |
| Body size | 1.18 m |
| Weight | 55 kg |
Elephant Robotics
Elephant Robotics