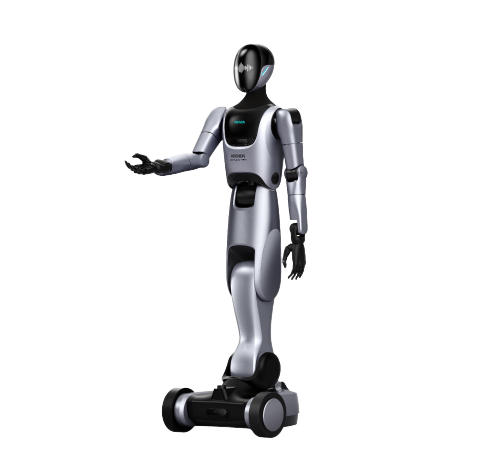
XMAN-L1
KEENON
 KEENON
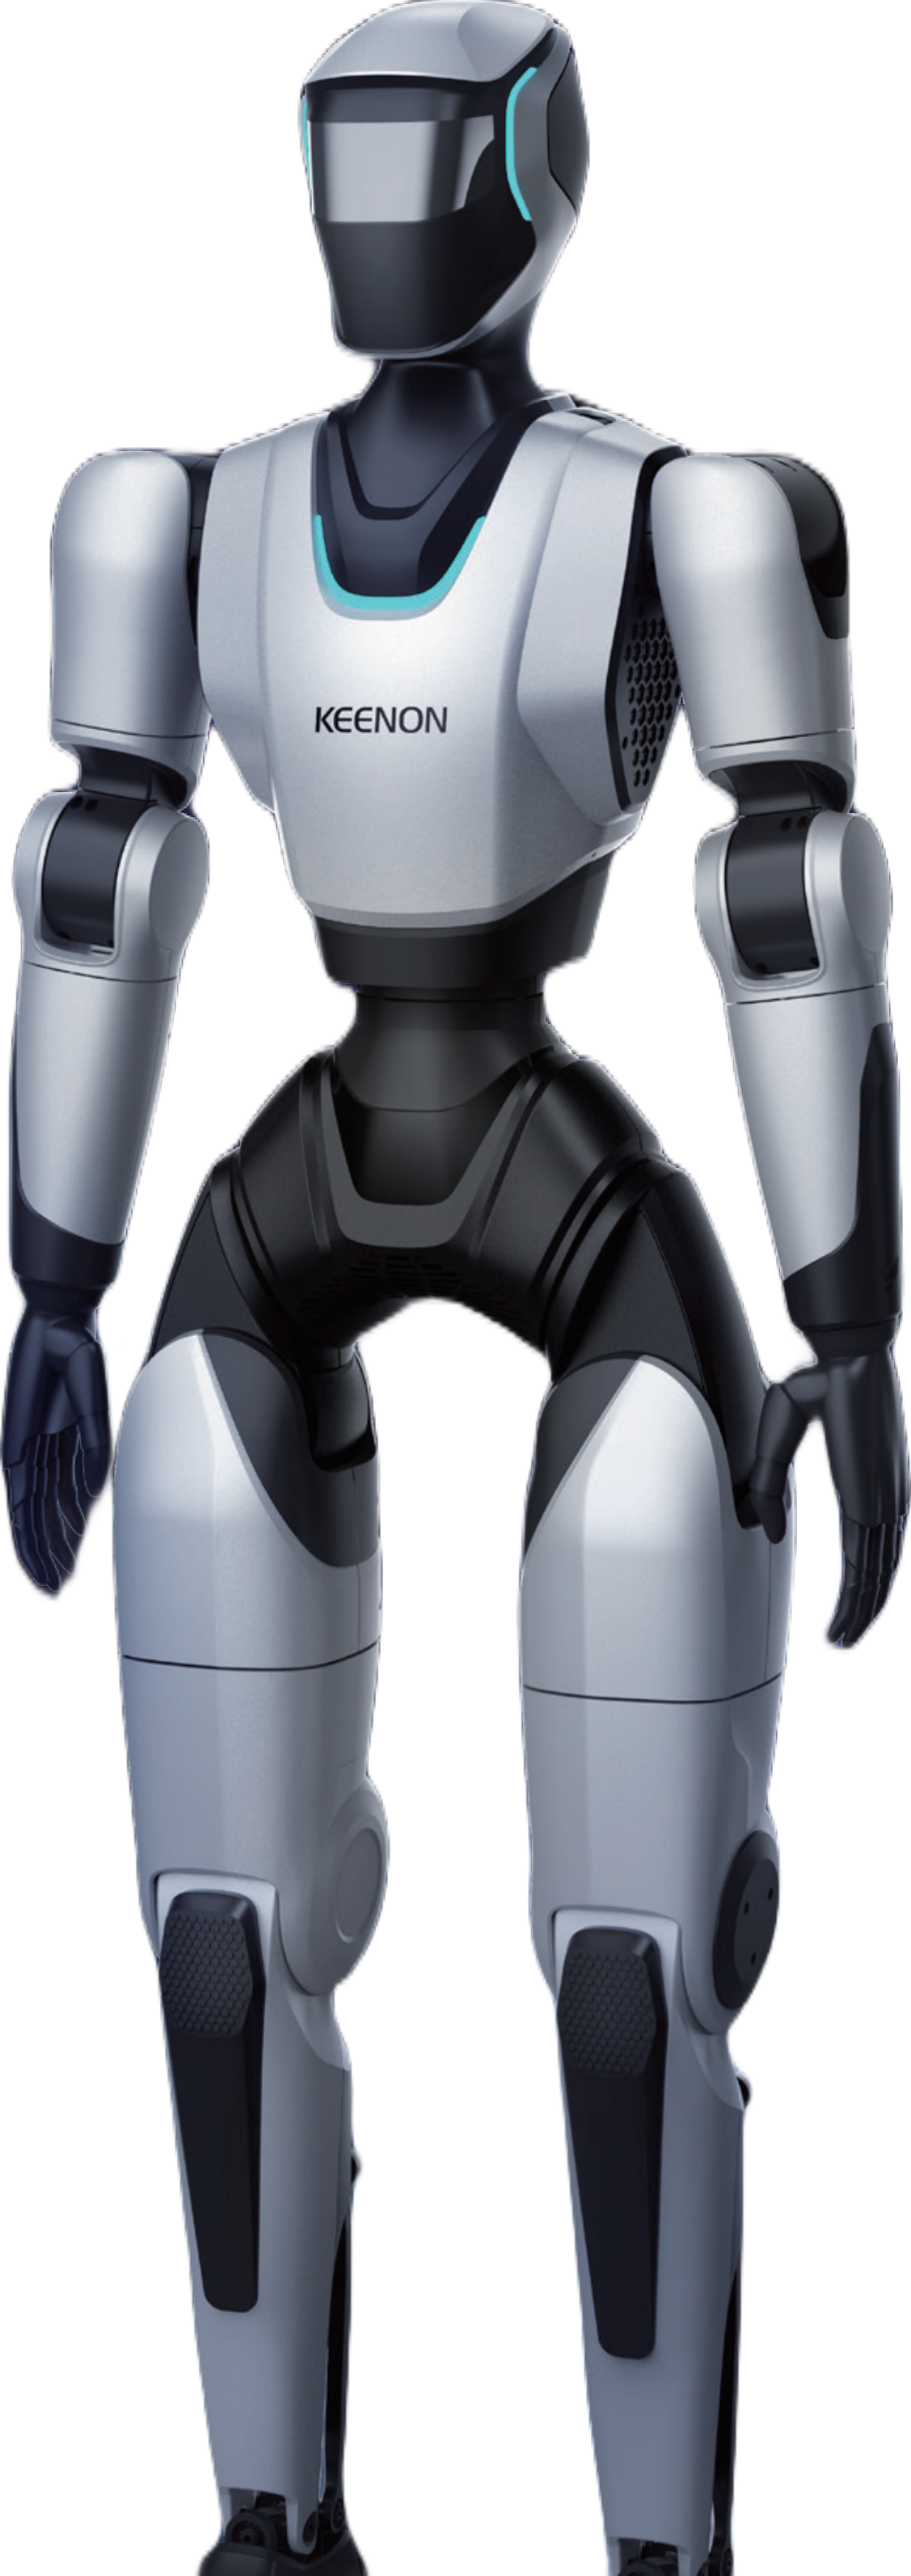
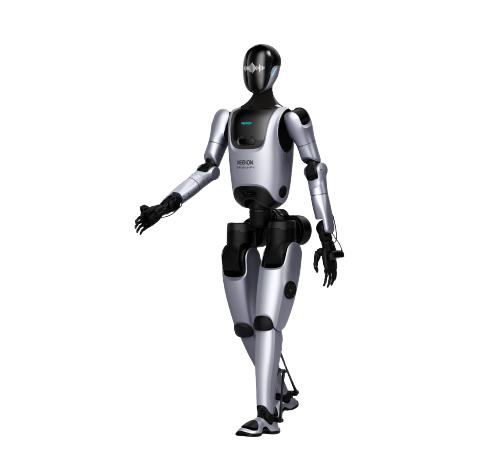
 XMAN-F1 is described as the world's first commercial bipedal humanoid service robot. Its human-inspired design is driven by deep reinforcement learning and a VLA foundation model for rapid iteration, built on a safety-first architecture. Multimodal fusion provides high-precision environment perception, and a fully in-house high-efficiency scheduling system supports multi-robot collaboration across scenarios. VR-based dual-arm teleoperation is supported.
| Hardware | XMAN-F1Contact sales |
|---|---|
| Computing | |
| Memory & storage | 64 GB |
| NPU edge compute | 275 TOPS |
| Actuation | |
| Full-body degrees of freedom | 43 DoF |
| Arm degrees of freedom | 7-DOF dual arms |
| Leg degrees of freedom | 6 DOF biped |
| Dexterous-hand degrees of freedom | 6 DOF x 2 |
| Waist degrees of freedom | 3 DOF |
| Head degrees of freedom | 2 DOF |
| Structure | |
| Body size | 175 cm |
| Weight | 68 kg |