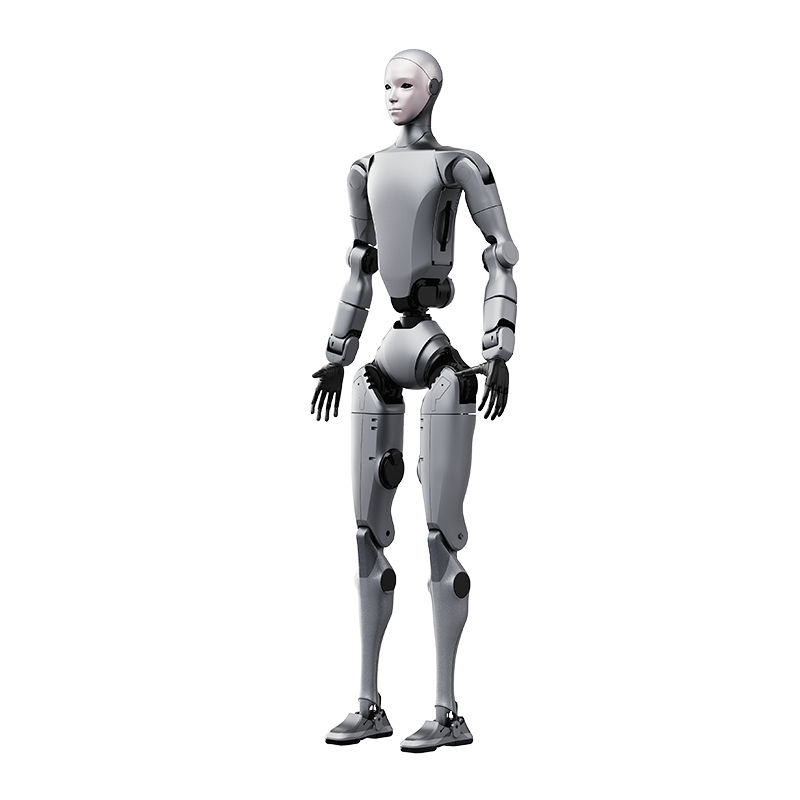
Unitree H2
Unitree
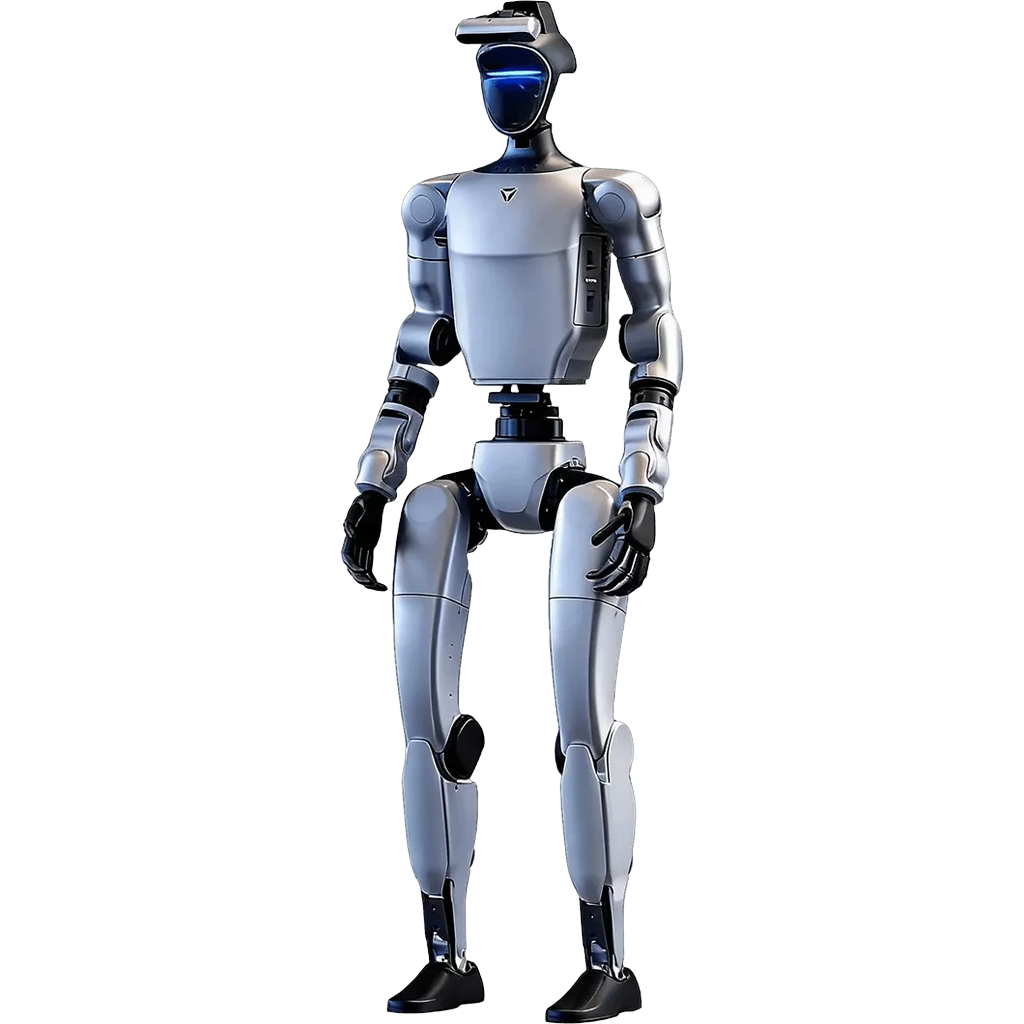
 Unitree
The Unitree G1-Comp is a humanoid football competition platform built for RoboCup, officially positioned as building a football superstar for competition. About 35 kg or more with the battery, standing 1320 x 450 x 200 mm, with 25-45 total degrees of freedom, 120 N·m maximum knee torque and about 2 hours of runtime. Based on the YOLO 11 algorithm it recognises the pitch environment quickly, working with the unitree_rl_gym reinforcement learning framework and Isaac Gym and MuJoCo simulation to cover the full Sim2Sim to Sim2Real pipeline; the SDK provides APIs for visual recognition, spatial localisation and motion control, compatible with the ROS ecosystem, with an optional Orin NX delivering 100 TOPS.
| Hardware | G1-CompNot listed |
|---|---|
| Sensing | |
| Cameras | Depth camera, 3D LiDAR |
| Microphones | 4-microphone array |
| Speakers | 5 w speaker |
| Computing | |
| Main processor | 8-core high-performance CPU |
| Actuation | |
| Full-body degrees of freedom | 25-45 |
| Arm degrees of freedom | 5 |
| Leg degrees of freedom | 6 |
| Dexterous-hand degrees of freedom | View full specification7 (force-controlled 3-finger dexterous hand Dex3-1 optional) + 2 (2 additional wrist DoF optional) |
| Waist degrees of freedom | 1+ (2 additional waist DoF optional) |
| Head degrees of freedom | 2 |
| Arm payload | approx. 3 Kg |
| Arm length | approx. 0.45 m |
| End effector | Force-controlled 3-finger dexterous hand Dex3-1 optional |
| Power | |
| Static runtime | approx. 2 h |
| Connectivity | |
| Wireless | Wi-Fi 6, Bluetooth 5.2 |
| Structure | |
| Body size | 1320 mm |
| Weight | approx. 35 kg+ |
Unitree
Unitree